“Quantity has a quality of its own.” — Joseph Stalin
Vector Fields and Line Integrals: A Visual and Mathematical Guide
A vector field is a mathematical construct where a vector $\vec{F}$ is assigned to each point (x, y) in a space. Specifically, in two-dimensional space $\mathbb{R}^2$, a vector field is often represented by a vector-valued function $\vec{F}(x,y)$. It is commonly expressed as $\vec{F}(x,y) = M(x, y)\hat{i} + N(x, y)\hat{j}$ where $M(x, y)$ and $N(x, y)$ are scalar functions representing the $x$ and $y$ components, and $\hat{i}$ and $\hat{j}$ are the standard unit vectors along the $x$-axis and $y$-axis. Alternatively, this can be written using angle bracket notation as $\vec{F} = \langle M, N \rangle$.
Vector fields are the mathematical backbone of classical physics and engineering. They model a vast array of phenomena, such as:
- Force fields: The direction and magnitude of electric, magnetic, or gravitational forces acting on a particle.
- Velocity fields: The speed and direction of fluid flow (like water in a river or air over an aircraft wing) at any given point in space.
Visualizing Standard Vector Fields
Vector fields can be visualized by plotting arrows across a Cartesian coordinate system. These arrows represent vectors with specific magnitudes and directions. The tail of each arrow sits at a specific point $(x,y)$, and the arrow points in the direction of $\vec{F}(x,y)$ with a length proportional to the vector’s magnitude.
Let’s examine four fundamental types of vector fields:
- Constant Vector Field: $\vec{F} = 2\hat{i} + \hat{j}$ (Figure 1). : This vector field does not depend on x and y. It assigns the same vector to every point in the plane. It is constant everywhere, meaning that all vectors have the same magnitude and direction (the field is uniform across the entire space).n Geometrically, this looks like a uniform breeze blowing steadily in one direction across the entire space.
- Linear Vector Field: $\vec{F} = x\hat{i}$ (Figure 2). This vector field depends linearly on the x coordinate. The arrows point in the direction of the x-axis. At $x = 0$ (the $y$-axis), the vectors have zero length. As you move to the right (positive $x$), they point right and grow longer. As you move to the left (negative $x$), they point left and grow longer in that direction, but it is independent of y.
- Radial Vector Field: $\vec{F} = x\hat{i} + y\hat{j}$ (Figure 3). In this field, the vector at any point $(x,y)$ is exactly the position vector of that point. The arrows point directly outward from the origin. The magnitude of the vectors increases linearly as you move further away, indicating that the field grows stronger with distance. This accurately models expansion or, if reversed, gravitational attraction toward a central mass.
- Rotational Vector Field: $\vec{F} = -y\hat{i} + x\hat{j}$ (Figure 4). This vector field is a rotational field, where each vector represents a counter-clockwise rotation around the origin. The transformation from $(x, y)$ to $ (−y, x)$ takes the position vector and rotates it exactly 90 degrees counter-clockwise. Therefore, at any point, the vector is tangent to a circle centered at the origin. This field models pure circulation (like a whirlpool).
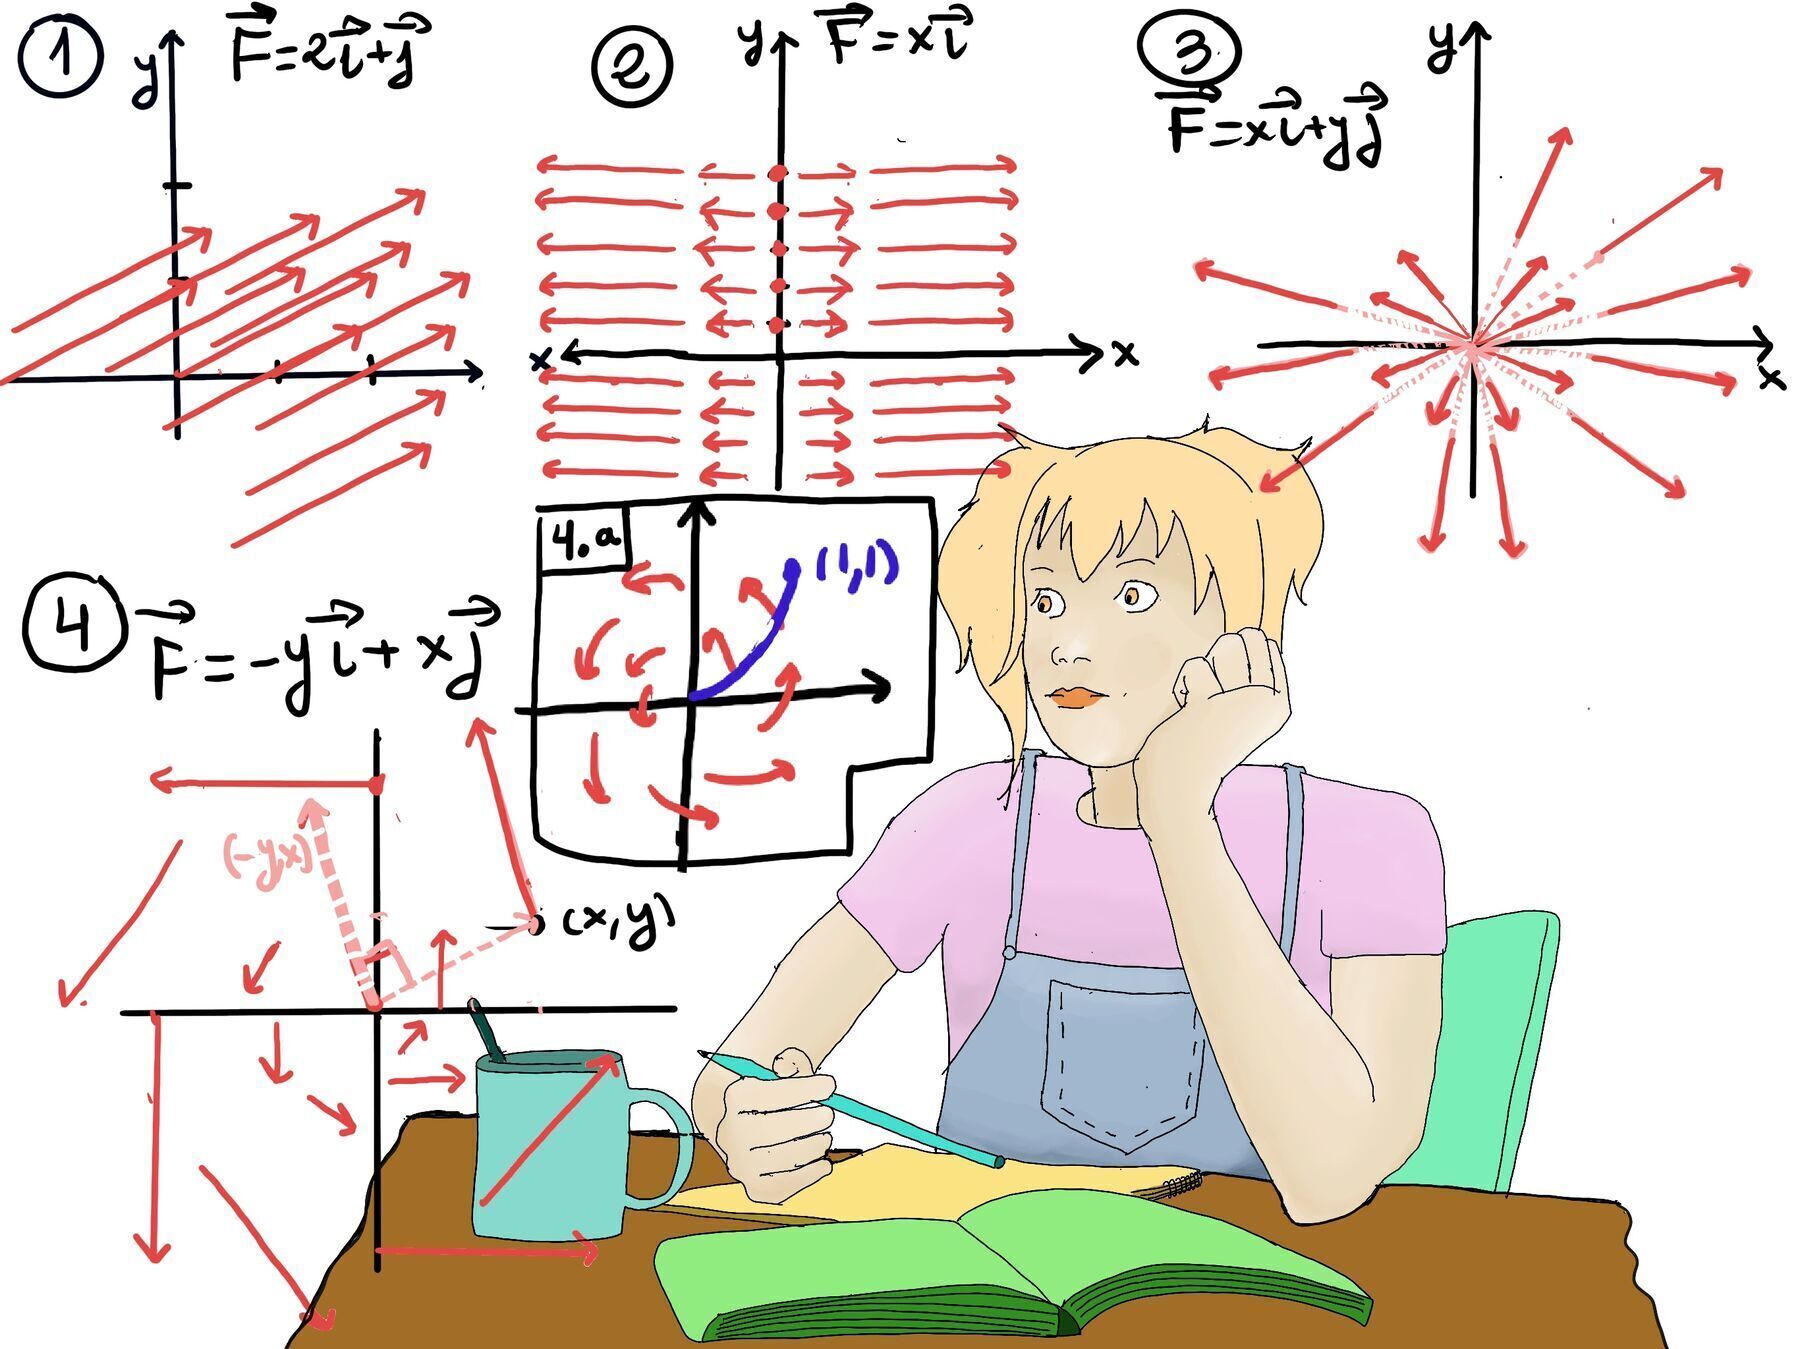
These illustrations help visualize how vector fields vary across space and provide insights into the behavior of different types of fields.
Work and Line Integrals
In physics, work is a fundamental concept that describes the transfer of energy when a force moves (or displaces) an object over a distance.
In its simplest form, when a constant force $\vec{F}$ acts on an object and is aligned with the direction of motion, the work done by a force $\vec{F}$ over a displacement $\Delta \vec{r}$ is calculated by the dot product of the force vector and the displacement vector: $W = \text{force} \cdot \text{ distance} = \vec{F} \cdot \Delta\vec{r}$. Here, the dot product means that work is the product of the magnitude of the force, the magnitude of the displacement, and the cosine of the angle between the force and displacement vectors.
It ensures that we are only multiplying the component of the force that acts exactly in the direction of motion.
However, the real world is rarely this simple. What happens if the path is a curve, and the force varies in magnitude and direction at every point along that curve? To solve this, we define work as the energy transferred by a force field moving an object along an arbitrary path $C$. We calculate this using a line integral: $W = \int_{C} \vec{F} \cdot d\vec{r}$
The line integral represents the sum of the work done by the force over each infinitesimal segment of the path. This integral can be understood as the sum of the dot products of the force vector and the infinitesimal displacement vectors along the path $C$. Consider breaking the curve $C$ into small segments $\Delta\vec{r_i}$, the work done can be approximated as: $W \approx \sum_{i=1}^{n} \vec{F} \cdot \Delta\vec{r}_i$. The work done over each segment can be approximated by the dot product of the force vector at that segment $\vec{F}$ and the segment’s displacement vector $\Delta\vec{r}_i$.
In the limit as the segment length $Δ\vec{r_i}$ approaches zero (i.e., as the segmentation becomes finer and finer), this Riemann sum perfectly converges into the line integral, W = $\int_{C} \vec{F} \cdot d\vec{r} = \lim_{\Delta r_i \to 0} \sum_{i=1}^{n} \vec{F}(\vec{r}_i) \cdot \Delta\vec{r}_i$.
To connect this with velocity, note that the displacement vector can also be expressed in terms of velocity. We know that displacement is velocity multiplied by time: $\Delta\vec{r}_i \approx \vec{v}(t_i)\Delta t = \frac{d\vec{r}}{dt}\Delta t$. Hence, the work integral can be rewritten as: $W = \lim_{\Delta t \to 0} \sum \vec{F}(\vec{r}(t))\cdot (\frac{d\vec{r}}{dt}Δt)$.
Recognizing that $\frac{d\vec{r}}{dt}$ is the velocity vector $\vec{v}$, we obtain: $W = \int_{t_1}^{t_2} \left( \vec{F}(\vec{r}(t)) \cdot \frac{d\vec{r}}{dt} \right) dt$ This shows that the work done by a force over a period from time $t_1$ to $t_2$ is the integral of the dot product of the force vector and the velocity vector over that time interval.
Evaluating Line Integrals
To evaluate a line integral, the standard method is to parameterize the path $C$ in terms of a single variable (usually $t$), and then substitute everything into the integral.
- A Polynomial Force Field. Consider a force field $\vec{F} = 2x\hat{i} + 3y\hat{j}$ and a path $C$ parameterized by $\vec{r}(t) = \langle t, t^2 \rangle$ where $0 \le t \le 1$. Calculate the work done by this force field along the path.
- Understand the Path. The path $\vec{r}(t) = \langle t, t^2 \rangle$ represents a parabola $y = x^2$ starting at the origin $(0, 0)$ and ending at $(1, 1)$.
- Find the Velocity Vector: Take the derivative of the position vector with respect to $t$:
$\frac{d\vec{r}}{dt} = \left\langle \frac{dx}{dt}, \frac{dy}{dt} \right\rangle = \langle 1, 2t \rangle$
- Evaluate the Force Field Along the Path: Substitute $x = t$ and $y = t^2$ into the force field equation:
$\vec{F}(\vec{r}(t)) = \langle 2(t), 3(t^2) \rangle = \langle 2t, 3t^2 \rangle$
- Compute the Dot Product and Integrate: Now, plug these into the line integral formula:
$W = \int_0^1 \left( \langle 2t, 3t^2 \rangle \cdot \langle 1, 2t \rangle \right) dt = \int_0^1 (2t(1) + 3t^2(2t)) dt = \int_0^1 (2t + 6t^3) dt$
$= \left[ t^2 + \frac{6t^4}{4} \right]_0^1 = 1 + \frac{3}{2} = \frac{5}{2}$.
- Conclusion. The total work done by the force field is exactly $\frac{5}{2}$ units.
Visualization:
- The path C is a parabolic path $y= x^2$ from (0, 0) to (1, 1).
- Force Field $\vec{F}$: Visualize vectors that increase in magnitude as you move away from the origin, with x and y components scaling linearly.
- Work Calculation: The integral calculates the total effect of the force along the curved path, accounting for both the magnitude and direction of the force and the displacement.
There is a highly useful alternative notation for line integrals. If we define our field and our differential displacement vector as: $\vec{F} = M\hat{i} + N\hat{j} = \langle M, N \rangle$, $d\vec{r} = dx\hat{i} + dy\hat{j} = \langle dx, dy \rangle$
Taking the dot product gives us $\vec{F} \cdot d\vec{r} = M\,dx + N\,dy$. This allows us to write the line integral in differential form: $W = \int_{C} \vec{F} \cdot d\vec{r} = \int_{C} M\,dx + N\,dy$
- Let’s re-evaluate a problem using this form. Given the rotational field $\vec{F} = -y\hat{i} + x\hat{j}$ and the same parabolic path $x = t$, $y = t^2$ ($0 \le t \le 1$) (Figure 4.a). Evaluate the work done by the force field $\vec{F}$ along the given path C.
- Understand the Path. The path $\vec{r}(t) = \langle t, t^2 \rangle$ represents a parabola $y = x^2$ starting at the origin $(0, 0)$ and ending at $(1, 1)$.
- Work done by the force field. The work W done by a force field $\vec{F}$ along a path C is given by the line integral: W = $\int_{C} \vec{F} \cdot d\vec{r} = \int_{t_1}^{t_2} (\vec{F} \cdot \frac{d\vec{r}}{dt} \cdot dt) = \int_{0}^{1} (\vec{F}\cdot \frac{d\vec{r}}{dt}dt)$
- Force Field Along the Path: $\vec{F} = \langle -y, x \rangle = \langle -t^2, t \rangle$. Besides, $dx = dt, dy =2tdt, \frac{d\vec{r}}{dt}= \langle \frac{dx}{dt}, \frac{dy}{dt} \rangle = \langle 1, 2t \rangle$.
$W = \int_{0}^{1} (\vec{F}·\frac{d\vec{r}}{dt}dt) =\int_{0}^{1} ⟨-t^2, t⟩ · ⟨1, 2t⟩ dt = \int_{0}^{1} (-t^2+2t^2)dt = \int_{0}^{1} t^2dt = \frac{t^3}{3}\bigg|_{0}^{1} = \frac{1}{3}$
Key Insight: A remarkable property of line integrals is parameterization invariance. The integral depends strictly on the geometric shape of the curve $C$, the direction of travel, and the vector field. If we parameterized the exact same geometric parabola using $x = \sin(\theta)$ and $y = \sin^2(\theta)$ for $0 \le \theta \le \pi/2$, the final integral would mathematically simplify to exactly $\frac{1}{3}$.
Geometrical interpretation
The line integral of a vector field $\vec{F}$ along a curve C is a way to calculate the total work done by the force field as an object moves along the curve. Mathematically, it is expressed as: $W = \int_{C} \vec{F} \cdot d\vec{r}$.
At any point on a smooth curve $C$, we can define a unit tangent vector, denoted as $\hat{\mathbf{T}}$. This is a normalized (it has a length of one) vector that is tangent to the curve at any given point. It is a vector that points in the direction of the curve’s forward motion.
If $s$ represents the arc length traveled along the curve, then an infinitesimally small step along the curve can be written as a scalar multiplication of the unit tangent vector and the tiny arc length distance $ds$: $d\vec{r} = \hat{\mathbf{T}} \, ds$
Substituting this into the work integral gives us the geometric formulation: $W = \int_{C} (\vec{F} \cdot \hat{\mathbf{T}}) ds$
What does this mean? The dot product $\vec{F} \cdot \hat{\mathbf{T}}$ is simply the scalar projection of the force field onto the direction of motion. The line integral continuously measures how much of the field is “pushing” you forward along your path, and accumulates that push over the total length $s$.
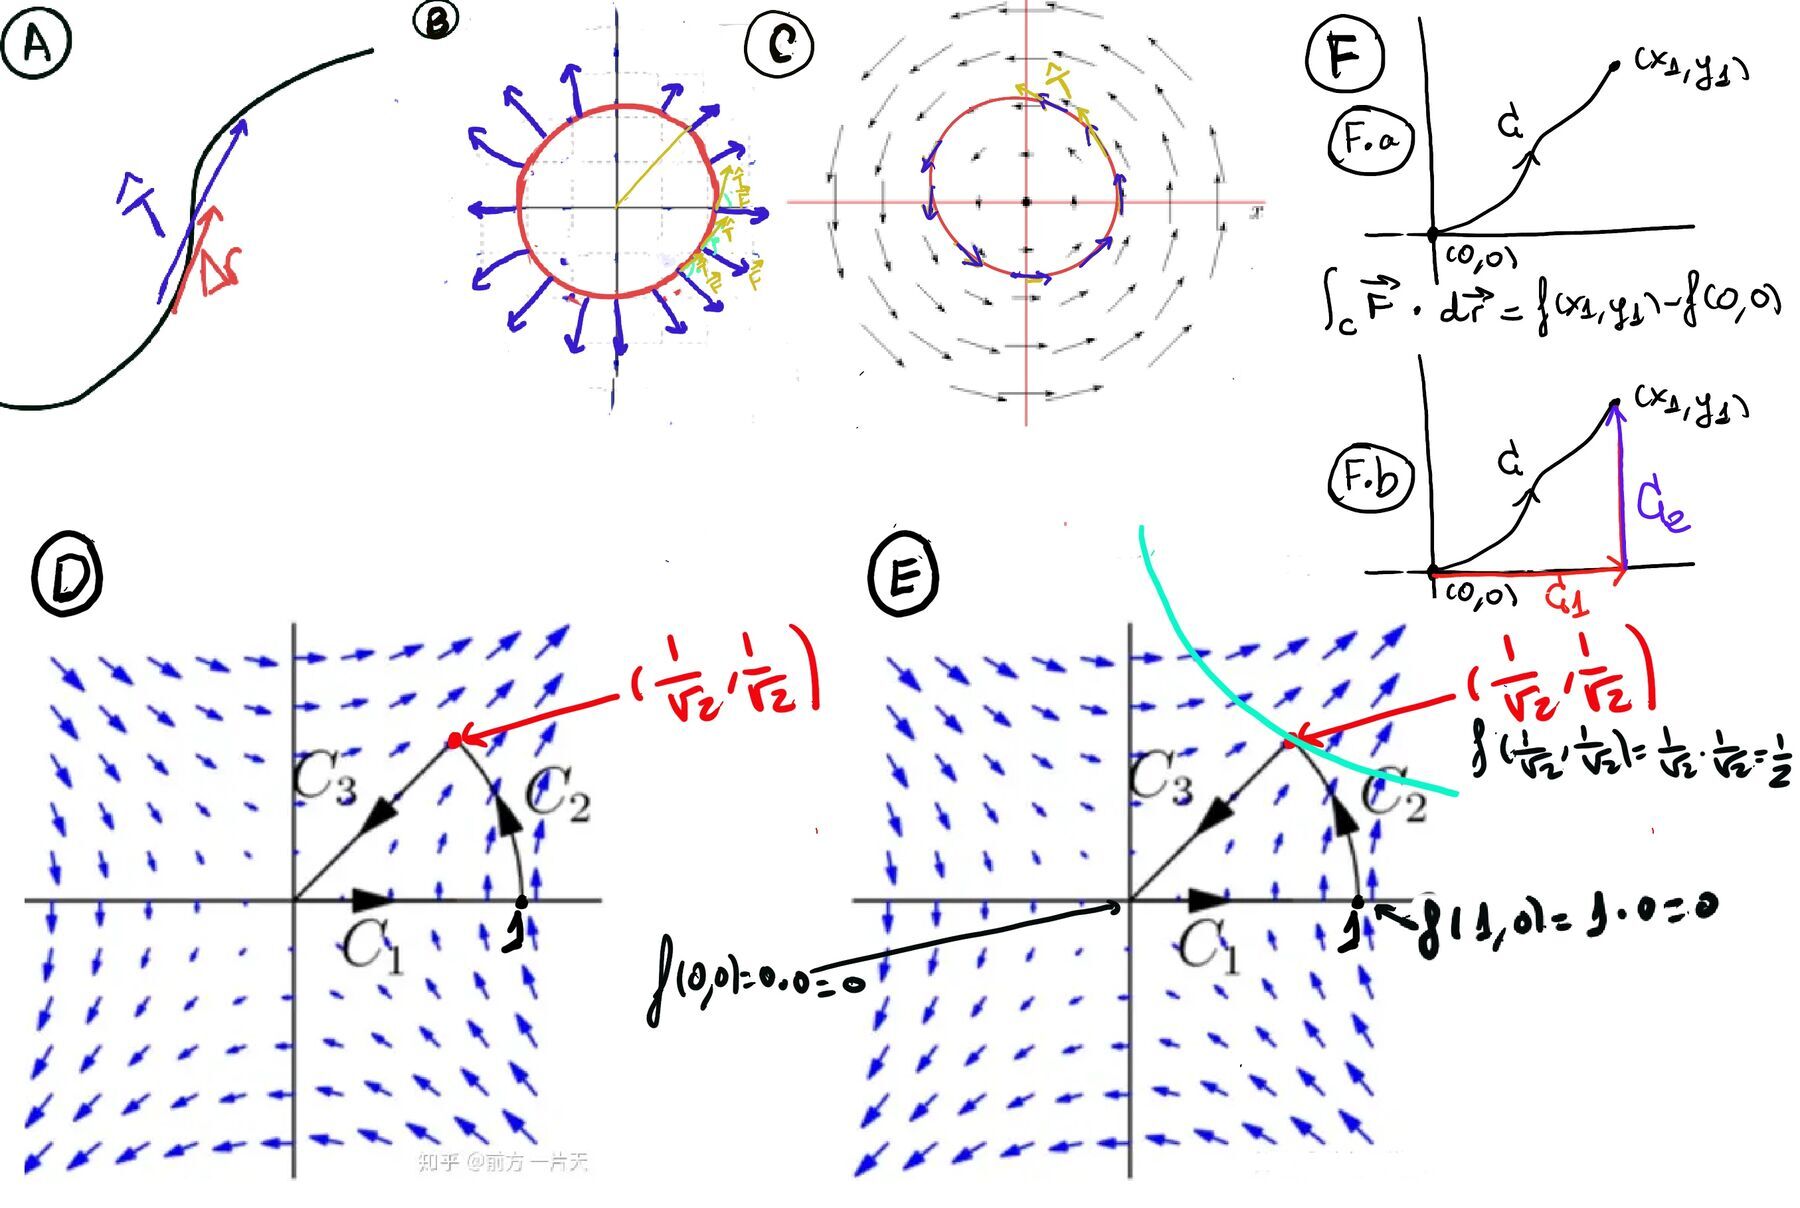
Examples and Geometrical Interpretation
- The Radial Field. Work Done by the Vector Field $\vec{F} = x\hat{i} + y\hat{j}$ along a Circular Path. Remember that this field points radially outward from the origin.
Consider a circle C of radius “a”. The curve is traversed counterclocwise. The vector field is given by $\vec{F} = x\vec{i} + y\vec{j}$. We want to compute the work done by the force as we move along the circle C.
Detailed Calculation.
- Parameterize the circle. The circle can be parameterized using: $x = a\cos(\theta), y = a\sin(\theta)$, where $0 \leq θ \leq 2 \pi$. The differentials are: $dx = −a\sin(\theta)d\theta, dy = a\cos(\theta)d\theta$.
- Compute the work integral. W = $\int_{C} \vec{F}\cdot d\vec{r} = \int_{C} Mdx + Ndy =\int_{C} xdx +ydy =[\text{Substituting the parameterization}] \int_{C} (a\cos(\theta))(-a\sin(\theta)d\theta) + a\sin(\theta)(a\cos(\theta)d\theta)$
Simplify: $\int_{0}^{2\pi}a^2(-\cos(\theta)\sin(\theta)+\sin(\theta)\cos(\theta))d\theta = \int_{0}^{2\pi} 0d\theta = 0.$
Geometric interpretation
Geometrically, the work done by the vector field $\vec{F}$ along the curve C can be intuitively understood by considering the relationship between the force vector and the direction of the motion and is zero because the force is perpendicular (point radially outward from the origin) to the motion (tangent to the circle) at every point on the circle (Figure B) ↭ $\vec{F} ⊥\hat{\mathbf{T}}⇒ \vec{F} · \hat{\mathbf{T}} = 0 ⇒\int_{C} \vec{F}·\hat{\mathbf{T}}·ds = 0$.
- Now consider the rotational field $\vec{F} = -y\vec{i} + x\vec{j}$ over the same circle C of radius “a” centered at the origin, traversed counterclockwise. The vector field is $\vec{F} = -y\vec{i} + x\vec{j}$ (Figure C). We are to compute the work done by this force field as we move along the circle C.
We established earlier that this field points in a counter-clockwise circle. In other words, it is a field that is tangential to the circle and parallel to the motion (the field is doing maximum possible work, pushing us along the path continuously): $\vec{F} \parallel \hat{\mathbf{T}} \implies \vec{F} \cdot \hat{\mathbf{T}} = |\vec{F}| ⇒ \int_{C} \vec{F}·\hat{\mathbf{T}}·ds = \int_{C} |\vec{F}|·ds = \int_{C} a·ds = a\int_{C}ds = a·length(C) = a\cdot 2\pi a = 2\pi a^2$. Hence, the work done by the force field is not zero.
Detailed Calculation.
- Parameterize the Circle: The circle can be parameterized using: $x = a\cos(\theta), y = a\sin(\theta)$, where $0 \leq \theta \leq 2\pi$. The differentials are: $dx = −a\sin(\theta)d\theta, dy = a\cos(\theta)d\theta$.
- Compute the work integral. W = $\int_{C} \vec{F}·d\vec{r} = \int_{C} Mdx + Ndy =\int_{C} -ydx +xdy =[\text{Substituting the parameterization:}] \int_{C} -(a\sin(\theta))(-a\sin(\theta)d\theta)+(a\cos(\theta))(a\cos(\theta))d\theta$
$=[\text{Simplifying:}] \int_{C} a^2(\sin^2(\theta)+\cos^2(\theta)) d\theta = \int_{0}^{2\pi} a^2d\theta = a^2\int_{0}^{2\pi} d\theta = a^2·2\pi$
- Calculate the work done by the vector field $\vec{F} = y\hat{i} + x\hat{j}$ as we move along a closed path $C$ consisting of three segments that enclose the sector $0 \le \theta \le \pi/4$ of the unit circle.
The total work is the sum of the work done along each individual segment: $C = C_1 + C_2 + C_3$ (Figure D).
The work done by the force $\vec{F}$ is given by: W = $\int_{C} \vec{F}·d\vec{r} = \int_{C_1} \vec{F}·d\vec{r} + \int_{C_2} \vec{F}·d\vec{r} + \int_{C_3} \vec{F}·d\vec{r} = \int_{C_1} (ydx+xdy) + \int_{C_2} (ydx+xdy) + \int_{C_3} (ydx+xdy)$
- Segment $C_1$: The horizontal line. This path travels along the $x$-axis from $(0, 0)$ to $(1, 0)$. Here, $y = 0$, which immediately means $dy = 0$. Substituting this into our integral, all terms vanish: $\int_{C_1} (ydx+xdy) = \int_{C_1} (0·dx+x·0) = \int_{C_1} 0 = 0$. Geometrically, the vector field is perpendicular to the motion along the x-axis ($F = \langle 0, x \rangle$), resulting in zero work.
- Segment $C_2$: The circular arc. This path is a portion of the unit circle from $(1, 0)$ to $(\frac{\sqrt{2}}{2}, \frac{\sqrt{2}}{2})$. Polar coordinates are the perfect tool here.
Let $x = \cos(\theta)$ and $y = \sin(\theta)$ for $0 \le \theta \le \pi/4$.
The differentials are $dx = -\sin(\theta)d\theta$ and $dy = \cos(\theta)d\theta$.
$\begin{aligned} \int_{C_2} y\,dx + x\,dy &= \int_{0}^{\pi/4} \Big( \sin(\theta)(-\sin(\theta)d\theta) + \cos(\theta)(\cos(\theta)d\theta) \Big) \\ &= \int_{0}^{\pi/4} (\cos^2(\theta) - \sin^2(\theta)) \, d\theta \\ &= \int_{0}^{\pi/4} \cos(2\theta) \, d\theta \\ &= \left[ \frac{1}{2}\sin(2\theta) \right]_0^{\pi/4} \\ &= \frac{1}{2}\sin\left(\frac{\pi}{2}\right) - \frac{1}{2}\sin(0) = \frac{1}{2} \end{aligned}$
- Segment $C_3$: The return line. This is a straight line from $A = (\frac{\sqrt{2}}{2}, \frac{\sqrt{2}}{2})$ back to the origin $B = (0, 0)$.
To parameterize any straight line from point $A$ to point $B$, use the standard formula: $\vec{r}(t) = (1-t)A + tB$ for $0 \le t \le 1$.
$x(t) = \frac{\sqrt{2}}{2}(1-t), \quad y(t) = \frac{\sqrt{2}}{2}(1-t)$
The differentials are $dx = -\frac{\sqrt{2}}{2}dt$ and $dy = -\frac{\sqrt{2}}{2}dt$. Because $x = y$ and $dx = dy$, we can substitute:
$\begin{aligned} \int_{C_3} y\,dx + x\,dy &= \int_0^1 \left( \frac{\sqrt{2}}{2}(1-t)\left(-\frac{\sqrt{2}}{2}dt\right) + \frac{\sqrt{2}}{2}(1-t)\left(-\frac{\sqrt{2}}{2}dt\right) \right) \\ &= \int_0^1 2 \left( -\frac{2}{4}(1-t) \right) dt \\ &= \int_0^1 (t - 1) \, dt \\ &= \left[ \frac{t^2}{2} - t \right]_0^1 = \frac{1}{2} - 1 = -\frac{1}{2} \end{aligned}$
- Total Work: Combining the three segments: $W_{\text{total}} = 0 + \frac{1}{2} - \frac{1}{2} = 0$.
- The Mathematician’s Shortcut (Conservative Fields): Notice that the total work around this closed loop is exactly zero. This is not a coincidence! The vector field $\vec{F} = \langle y, x \rangle$ is a conservative vector field because it is the gradient of a scalar potential function: $f(x,y) = xy$. By the Fundamental Theorem of Line Integrals, the work done on any closed loop in a conservative field is always zero.
- Calculate the work done by the vector field $\vec{F} = \langle xy^2, 2xy \rangle$ along the smaller arc of $x^2 + y^2 = 1$ from $(1, 0)$ to $(0, -1)$.
The path C is part of the circle $x^2 + y^2 = 1$. The points (1, 0) and (0, −1) are on this circle. The smaller arc of this circle that goes from (1, 0) to (0, −1) corresponds to moving clockwise. For a circle of radius 1, a general parametrization is: $x(t) = \cos(t), y(t) = \sin(t)$, where t ranges over the interval corresponding to the points on the arc.

- Parametrized the smaller arc. Since we are moving clockwise from $(1, 0)$ to $(0, −1)$, the correct parametrization that reflects the clockwise motion is: $x = \cos(t), y = -\sin(t)$ where $0 \leq t \leq \frac{\pi}{2},$ i.e., t ranges from t = 0 (corresponding to (1, 0)) to t = $\frac{\pi}{2}$ (corresponding to (0, -1)) (Refer to Figure ii for a visual representation and aid in understanding it). The differentials are $dx = -\sin(t)dt, dy = -\cos(t)dt$.
- Set up the work integral. The work done by the vector field $\vec{F} = ⟨M, N⟩=⟨xy^2, 2xy⟩$ along the path C is given by W = $\int_{C} \vec{F}·d\vec{r} = \int_{C} Mdx + Ndy =\int_{C} xy^2dx +2xydy$.
Substituting the parameterization: $\int_{0}^{\frac{\pi}{2}} \cos(t)\sin^2(t)(-\sin(t)dt)+2\cos(t)(-\sin(t))(-\cos(t)dt)$
Simplifying: $\int_{0}^{\frac{\pi}{2}} (-sin^3(t)cos(t)+2cos^2(t)sin(t))dt = \int_{0}^{\frac{\pi}{2}} -sin^3(t)cos(t)dt + \int_{0}^{\frac{\pi}{2}} 2\cos^2(t)\sin(t)dt$
Let’s use substitution (first integral): $u = \sin(t), du = \cos(t)dt$ & (second part) $v = \cos(t), dv = -\sin(t)dt$.
$\int_{0}^{\frac{\pi}{2}} -u^3dt + \int_{0}^{\frac{\pi}{2}} - 2v^2dv = -\frac{u^4}{4}-\frac{2v^3}{3}\bigg|_{0}^{\frac{\pi}{2}}$
$-\frac{1}{4}\sin^4(t)-\frac{2}{3}\cos^3(t)\bigg|_{0}^{\frac{\pi}{2}} = \frac{-1}{4}-(-\frac{2}{3}) = \frac{-1}{4}+\frac{2}{3} = \frac{-3}{12}+\frac{8}{12} = \frac{5}{12}$
- Calculate the work done by the field $\vec{F} = \langle x\sin(y), y \rangle$ along the curve $y = x^2$ from $(-1, 1)$ to $(2, 4)$.
-
Parametrize the curve C. $x = t, y = t^2$ where t ranges from -1 to 2. When t = −1, x = −1 and y = 1, so the point is (−1, 1). When t = 2, x = 2 and y = 4, so the point is (2, 4). The differentials are $dx = dt, dy = 2tdt$.
-
Set up the work integral. The work done by the vector field $\vec{F} = \langle M, N \rangle = \langle x\sin(y), y \rangle$ along the path C is given by $W = \int_{C} \vec{F} \cdot d\vec{r} = \int_{C} Mdx + Ndy =\int_{C} x\sin(y)dx+ydy$.
Substituting the parameterization. $\int_{-1}^{2} (t\sin(t^2))dt +t^2(2tdt) =[\text{Simplify}] \int_{-1}^{2} (t\sin(t^2)+2t^3)dt$
-
Evaluate.
First integral: $\int_{-1}^{2} t\sin(t^2)dt =[u = t^2, du = 2tdt] \frac{1}{2}\int_{-1}^{2} sin(u)du = \frac{-1}{2}cos(u) = \frac{-1}{2}cos(t^2)\bigg|_{-1}^{2} = \frac{-1}{2}[cos(4)-cos(1)]$
Second integral: $\int_{-1}^{2} 2t^3dt = 2\frac{t^4}{4} = \frac{t^4}{2}\bigg|_{-1}^{2} = \frac{16}{2}-\frac{1}{2} = \frac{15}{2}$
-
Conclusion. $W = \int_{C} \vec{F}·d\vec{r} = \int_{C} Mdx + Ndy =\int_{C} x\sin(y)dx+ydy = \frac{-1}{2}\cos(4)+\frac{1}{2}\cos(1)+\frac{15}{2}$
Bibliography
This content is licensed under a Creative Commons Attribution-NonCommercial-ShareAlike 4.0 International License and is based on MIT OpenCourseWare [18.01 Single Variable Calculus, Fall 2007].
- NPTEL-NOC IITM, Introduction to Galois Theory.
- Algebra, Second Edition, by Michael Artin.
- LibreTexts, Calculus and Calculus 3e (Apex). Abstract and Geometric Algebra, Abstract Algebra: Theory and Applications (Judson).
- Field and Galois Theory, by Patrick Morandi. Springer.
- Michael Penn, and MathMajor.
- Contemporary Abstract Algebra, Joseph, A. Gallian.
- YouTube’s Andrew Misseldine: Calculus. College Algebra and Abstract Algebra.
- MIT OpenCourseWare 18.01 Single Variable Calculus, Fall 2007 and 18.02 Multivariable Calculus, Fall 2007.
- Calculus Early Transcendentals: Differential & Multi-Variable Calculus for Social Sciences.



