
|
 |

|
|
|
|
|
|
All things are difficult before they are easy, Thomas Fuller.
Curiosity is the driving force between knowledge and discovery, Arturo Pérez Reverte.
What about the future?" “We’ll talk about the future when it gets here,” Arturo Perez Reverte.
Before we dive into one of the most profound theorems in calculus, let’s establish our foundation.
A vector field is an assignment of a vector $\vec{F}$ to each point $(x, y)$ in space. In two dimensions, this looks like $\vec{F} = M\vec{i}+N\vec{j}$ where $M$ and $N$ are functions of $x$ and $y$. In three dimensions, we add a vertical component: $\vec{F} = P\hat{\mathbf{i}} + Q\hat{\mathbf{j}} + R\hat{\mathbf{k}}$.
A vector field can be visualized as a space filled with arrows, each attached to a point. These arrows represent vectors with specific magnitudes and directions, e.g., currents in an ocean or prevailing winds.
Work is defined as the energy transferred when a force acts on an object and displaces it along a path. In the context of vector fields, we calculate the work done by a force field along a curve or trajectory $C$ using a line integral. The work done by a force field $\vec{F}$ along a curve $C$ is: $\operatorname{W} = \int_{C} \vec{F} \cdot d\vec{r} = \int_{C} Mdx + Ndy = \int_{C} \vec{F} \cdot \hat{\mathbf{T}}ds$, where $d\vec{r} = \langle dx, dy, dz \rangle$ is an infinitesimal vector tangent to the curve and $\hat{\mathbf{T}}$ is the unit tangent vector. The dot product guarantees we only calculate the force pushing exactly in the direction of motion.
A vector field is conservative if there exists a scalar function $f$ such that $\vec{F} = \nabla f$ (the vector field is its gradient). This scalar function is known or referred to as the potential function associated with the vector field.
Theorem. Fundamental Theorem of Calculus for Line Integrals. If $\vec{F}$ is a conservative vector field in a simply connected region of space (i.e., a region with no topological holes or tunnels), and if $f$ is a scalar potential function for $\vec{F}$ in that region, then $\int_{C} \vec{F} \cdot d\vec{r} = \int_{C} \nabla f \cdot d\vec{r} = f(P_1)-f(P_0)$ where $P_0$ and $P_1$ are the initial and final points of the curve $C$, respectively.
The line integral of the vector field $\vec{F}$ along the curve $C$ is defined as: $\int_{C} \vec{F} \cdot d\vec{r}$ where $d\vec{r}$ is an infinitesimal vector tangent to the curve, given by: $d\vec{r} = \langle dx, dy, dz \rangle$.
$\int_{C} \vec{F} \cdot d\vec{r} = \int_{a}^{b} (P\frac{dx}{dt} + Q\frac{dy}{dt} + R\frac{dz}{dt})dt = \int_{a}^{b} (P(x(t), y(t), z(t))\frac{dx}{dt} + Q(x(t), y(t), z(t))\frac{dy}{dt} + R(x(t), y(t), z(t))\frac{dz}{dt})dt$
Furthermore, we defined the curl of a 3D vector field as the cross product of the del operator ($\nabla$) and the field itself. It measures the microscopic rotation at any point:
$\operatorname{curl}(\vec{F}) = \nabla \times \vec{F} = \begin{vmatrix}\hat{\mathbf{i}} & \hat{\mathbf{j}} & \hat{\mathbf{k}}\\\ \frac{\partial }{\partial x} & \frac{\partial }{\partial y} & \frac{\partial }{\partial z}\\\ P & Q & R\end{vmatrix} = (\frac{\partial R}{\partial y}-\frac{\partial Q}{\partial z})\hat{\mathbf{i}}-(\frac{\partial R}{\partial x}-\frac{\partial P}{\partial z})\hat{\mathbf{j}} + (\frac{\partial Q}{\partial x}-\frac{\partial P}{\partial y})\hat{\mathbf{k}}$
Theorem. The curl of a conservative field is the zero vector, $\vec{0}$. Conversely, if $\operatorname{curl}(\vec{F}) = \vec{0}$, the components $P, Q$, and $R$ have continuous first-order partial derivatives, and its domain is open and simply-connected, the vector field is conservative.

Stokes’ Theorem is a crowning achievement of multivariable calculus. It bridges the gap between two seemingly entirely different mathematical concepts: the line integral of a vector field around a 1D boundary curve, and the surface integral of the field’s curl over a 2D surface bounded by that curve.
It states that the line integral of a vector field $\vec{F}$ around a simple, closed curve $C$ is equal to tbe surface integral of the curl of that vector field over a surface $S$ bounded by that curve $C$. $S$ is any surface bounded by $C$.
Given a continuous, differentiable vector field $\vec{F}$, an oriented smooth surface $S$, and a simple, closed boundary curve $C$ that encloses $S$, Stokes’ Theorem asserts that: $\oint_C \vec{F} \cdot d\vec{r} = \iint_{S} (\nabla \times \vec{F}) \cdot \hat{\mathbf{n}} \, dS$ where:
It states that the total circulation (line integral) of the vector field $\vec{F}$ around the closed curve $C$ (how much the vector field flows along the curve) is equal to the flux (surface integral) of the curl of that vector field through any surface $S$ bounded by the curve (how much the field is spinning or rotating across the surface)..
In simple terms, Stokes’ Theorem equates the macroscopic circulation around the boundary of a surface to the total amount of microscopic rotations (the curl) of the field over the surface itself.
To visualize this, imagine dipping a circular wire ring into a bucket of soap.
Imagine dropping millions of microscopic paddlewheels into the soap film. The vector field’s curl makes these tiny wheels spin. In the interior of the soap film, adjacent paddlewheels spin against each other, canceling out their internal friction. However, at the very edge of the soap film, the paddlewheels touch the wire ring. Because there is no neighboring wheel to cancel out the motion on the outside, their rotation physically drives a current along the wire.
Therefore, summing up all the tiny microscopic spins across the entire soap film (the surface integral) perfectly equals the total flow measured moving around the wire ring (the line integral).
Mind-Bending Fact: It does not matter if the soap film is perfectly flat, or if you blow into it so it billows out like a parachute. As long as the film is attached to the wire ring, the total flux of the curl through the bubble will exactly equal the line integral around the ring!
An important aspect of applying Stokes’ Theorem is ensuring the correct orientation of the surface $S$ and the curve $C$. The orientation must be chosen such that the surface and curve are compatible, meaning the surface normal and the direction of the curve are aligned properly.
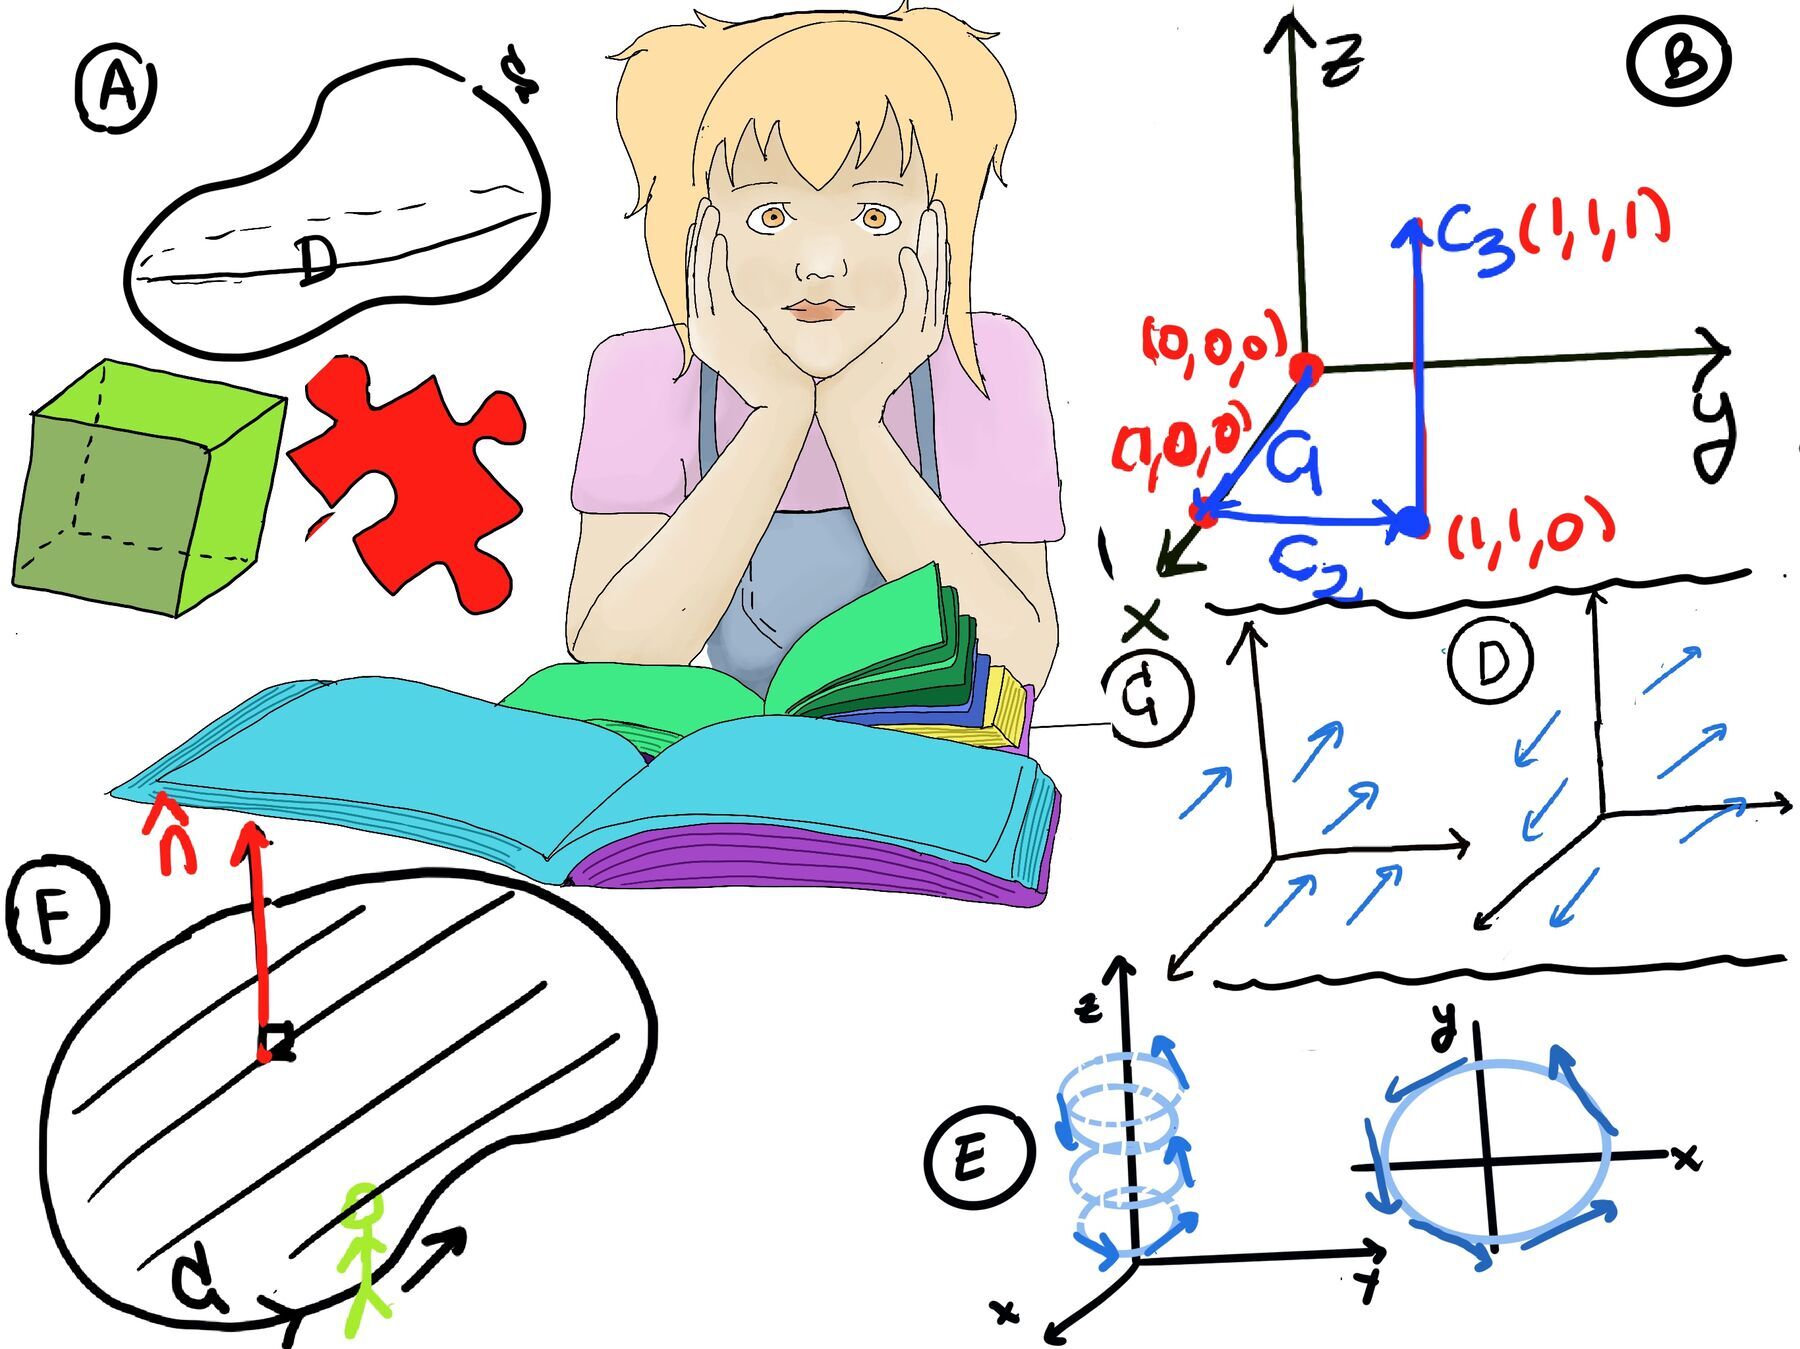
In particular, the direction of the normal vector $\hat{\mathbf{n}}$ must be chosen so that it is compatible with the orientation of the curve and the surface. If you traverse the curve $C$ in the positive direction with the surface on your left-hand side, then the normal vector $\hat{\mathbf{n}}$ to the surface must point upwards (away from the surface) (Figure F).
Orientation and the Right-Hand Rule. A mnemonic, trick, or useful way to remember this is by using the right hand rule: align your thumb along the direction of the curve positively, the index finger tangent to the surface $S$ and towards the interior of the surface, and the middle finger will point in the direction of the normal vector $\hat{\mathbf{n}}$ (Figures i and ii).
We parameterize the unit circle $C$:
We substitute these into the line integral $\int P\,dx + Q\,dy + R\,dz$: $\oint_C \vec{F} \cdot d\vec{r} = \int_{0}^{2\pi} \left( -\sin(t)(-\sin(t)) + \cos(t)(\cos(t)) + 0 \right) dt$
$\oint_C \vec{F} \cdot d\vec{r} = \int_{0}^{2\pi} (\sin^2(t) + \cos^2(t)) dt = \int_{0}^{2\pi} 1 \, dt = 2\pi$
First, compute the curl of $\vec{F}$: $\nabla \times \vec{F} = \begin{vmatrix} \hat{\mathbf{i}} & \hat{\mathbf{j}} & \hat{\mathbf{k}} \\ \frac{\partial}{\partial x} & \frac{\partial}{\partial y} & \frac{\partial}{\partial z} \\ -y & x & 0 \end{vmatrix} = \langle 0, 0, 2 \rangle$
According to Stokes’ Theorem, we can choose any surface bounded by $C$. Calculating the normal vectors for the curved hemisphere is tedious. Because the boundary is just the flat circle on the xy-plane, let’s choose the simplest possible soap bubble: the flat disk $S'$ at $z=0$.
For a flat disk on the xy-plane, the upward-pointing normal vector is simply $\hat{\mathbf{n}} = \langle 0, 0, 1 \rangle$.
$(\nabla \times \vec{F}) \cdot \hat{\mathbf{n}} = \langle 0, 0, 2 \rangle \cdot \langle 0, 0, 1 \rangle = 2$
Now, evaluate the double integral over the area of the flat disk:
$$\iint_{S'} (\nabla \times \vec{F}) \cdot \hat{\mathbf{n}} \, dS = \iint_{S'} 2 \, dS = 2 \iint_{S'} dS$$The term $\iint dS$ is exactly the geometric area of the unit circle, which is $\pi(r^2) = \pi(1^2) = \pi$. $2(\pi) = 2\pi$
The Conclusion: The line integral yields $2\pi$, and the surface integral yields $2\pi$. Stokes’ Theorem holds perfectly!
Stokes’ Theorem is not just a mathematical curiosity. It is the bridge between microscopic laws of nature (expressed with derivatives), and macroscopic, engineerable quantities (voltages, currents, fluxes).
Without this bridge, Maxwell’s equations would describe beautiful differential geometry but no generator, transformer, or electric motor would work. Stokes’ Theorem is the translator that turns local curls into global circulation.
Physics begins with the local statement: $\nabla \times \vec{E} = -\frac{\partial \vec{B}}{\partial t}$. In words, a changing magnetic field creates a swirling electric field.
But this is a pointwise statement. It tells you what happens at each infinitesimal location in space. Engineers cannot build “infinitesimal loops.” They build real coils of wire. So how do you go from the microscopic swirl of $\vec{E}$ to the actual voltage in a physical loop?
Apply Stokes’ Theorem: $\oint_C \vec{E}\cdot d\vec{r} = \iint_S (\nabla \times \vec{E})\cdot \vec{n}\, dS$
Insert Faraday’s Law: $\oint_C \vec{E}\cdot d\vec{r} = \iint_S \left(-\frac{\partial \vec{B}}{\partial t}\right)\cdot \vec{n}\, dS$
Now interpret each side:
Stokes' Theorem provides the exact mathematics explaining how spinning a magnet near a coil of wire generates the electricity that powers our homes, computers, and cities.
In multivariable calculus, Stokes’ Theorem acts as a mathematical bridge. It proves that the total circulation of a vector field along a closed boundary curve $C$ is exactly equal to the total flux of the field’s curl passing through any surface $S$ that is bounded by $C$. $\boxed{\oint_C \vec{F} \cdot d\vec{r} = \iint_{S} (\nabla \times \vec{F}) \cdot \hat{\mathbf{n}} \, dS}$
Let’s choose the simplest possible surface bounded by the unit circle $C$: the flat unit disk lying perfectly in the $xy$-plane ($z = 0$).
Step 1: Compute the Curl of $\vec{F}$
Compute the curl of $\vec{F}$. The curl measures the microscopic rotation of the field: $\operatorname{curl}(\vec{F}) = \nabla \times \vec{F} = \begin{vmatrix} \hat{\mathbf{i}} & \hat{\mathbf{j}} & \hat{\mathbf{k}} \\ \frac{\partial}{\partial x} & \frac{\partial}{\partial y} & \frac{\partial}{\partial z} \\ y & z & x \end{vmatrix}$
Evaluating the determinant: $\nabla \times \vec{F} = \left( \frac{\partial}{\partial y}(x) - \frac{\partial}{\partial z}(z) \right)\hat{\mathbf{i}} - \left( \frac{\partial}{\partial x}(x) - \frac{\partial}{\partial z}(y) \right)\hat{\mathbf{j}} + \left( \frac{\partial}{\partial x}(z) - \frac{\partial}{\partial y}(y) \right)\hat{\mathbf{k}}$
$\nabla \times \vec{F} = \langle 0 - 1, -(1 - 0), 0 - 1 \rangle = \langle -1, -1, -1 \rangle$
Step 2: Set Up the Surface Integral
Since our chosen surface $S$ is a flat disk lying on the $xy$-plane, its unit normal vector points straight up: $\hat{\mathbf{n}} = \hat{\mathbf{k}} = \langle 0, 0, 1 \rangle$. The differential surface area $dS$ is simply the flat area element $dx\,dy$.
Calculate the dot product of the curl and the normal vector: $(\nabla \times \vec{F}) \cdot \hat{\mathbf{n}} = \langle -1, -1, -1 \rangle \cdot \langle 0, 0, 1 \rangle = -1$
Now, evaluate the surface integral: $\int \int_{S} (\nabla \times \vec{F}) \cdot \hat{\mathbf{n}}dS = \int \int_{S} (-1)dxdy$
The term $\iint_{S} dx\,dy$ is simply the geometric area of the unit disk $S$. Because the radius is 1, the area is $\pi(1^2) = \pi$.
Therefore, $\text{Surface Integral} = -1(\pi) = -\pi$
Now let’s calculate the left side of Stokes’ Theorem by measuring the flow directly along the circular wire.
$\int_{0}^{2\pi} -\sin^2(t)$ =[Using the identity $\sin^2(t)=\frac{1-\cos(2t)}{2}$] $-\int_{0}^{2\pi} \frac{1-\cos(2t)}{2}dt = \frac{-1}{2}(\int_{0}^{2\pi}1dt - \int_{0}^{2\pi} \cos(2t)dt)$
The integral of $\cos(2t)$ over a full period $[0, 2\pi]$ is zero, $\int_{0}^{2\pi} \cos(2t)dt = 0$
$\frac{-1}{2}\int_{0}^{2\pi}1dt = \frac{-1}{2}t\bigg|_{0}^{2\pi} = \frac{-1}{2}2\pi = -\pi$
Both the surface integral and the line integral yield the same result, confirming Stokes’ Theorem.

Stokes’ Theorem states that: $\oint_C \vec{F} \cdot d\vec{r} = \int \int_{S} (\nabla \times \vec{F}) \cdot \hat{\mathbf{n}}dS$
Parametrize the curve $C$. The boundary curve $C$ is the intersection of the surface $z = 4 -x^2-y^2$ (paraboloid) and the cylinder (like a soda can) $x^2 + y^2 = 1$. At the boundary (intersection), $z = 4 - 1 = 3$, so $C$ lies in the plane $z = 3$. The surface $S$ is the part of the upside-down bowl inside the cylinder (soda can), which is above z = 3, where the bowl and the soda can (cylinder) intersect.
The parametrization of the curve $C$ is $\vec{r}(t)= \langle \cos(t), \sin(t), 3\rangle $, $0 \leq t \leq 2\pi$.
Evaluate $\vec{F}$ on $C$: $\vec{F}(\vec{r}(t)) = \langle 2\sin(t), -3, 3\rangle $
Compute $d\vec{r}$: $d\vec{r} = \frac{d\vec{r}}{dt}dt = \langle -\sin(t), \cos(t), 0\rangle dt$
Compute the line integral: $\oint_C \vec{F} \cdot d\vec{r} = \int_{0}^{2\pi} \langle 2\sin(t), -3, 3\rangle ·\langle -\sin(t), \cos(t), 0\rangle dt = \int_{0}^{2\pi} (-2sin^2(t)-3cos(t))dt = -2\int_{0}^{2\pi} \sin^2(t)dt -3\int_{0}^{2\pi} \cos(t)dt$
We already know that the integral of $\cos(2t)$ over a full period $[0, 2\pi]$ is zero: $\int_{0}^{2\pi} \cos(2t)dt = 0$
$-2\int_{0}^{2\pi} \sin^2(t)dt$ =[We use the identity $\sin^2(t)=\frac{1-\cos(2t)}{2}$] $-2\frac{1}{2} \int_{0}^{2\pi} (1 -\cos(2t))dt = -\int_{0}^{2\pi} dt = -t\bigg|_{0}^{2\pi}$
$= -2\pi$ since we know that $\int_{0}^{2\pi} \cos(2t)dt = 0$.
To verify the theorem, we now evaluate $\int \int_{S} (\nabla \times \vec{F}) \cdot \hat{\mathbf{n}}dS$. In other words, we now evaluate the flux of the curl through the curved paraboloid roof.
Compute the curl of $\vec{F}$ $\operatorname{curl}(\vec{F}) = \nabla \times \vec{F} = \begin{vmatrix}\hat{\mathbf{i}} & \hat{\mathbf{j}} & \hat{\mathbf{k}}\\\ \frac{\partial }{\partial x} & \frac{\partial }{\partial y} & \frac{\partial }{\partial z}\\\ 2y & -z & 3\end{vmatrix} = (\frac{\partial 3}{\partial y}-\frac{\partial (-z)}{\partial z})\hat{\mathbf{i}}-(\frac{\partial 3}{\partial x}-\frac{\partial 2y}{\partial z})\hat{\mathbf{j}} + (\frac{\partial (-z)}{\partial x}-\frac{\partial 2y}{\partial y})\hat{\mathbf{k}}$
$\nabla \times \vec{F} = \left( 0 - (-1) \right)\hat{\mathbf{i}} - \left( 0 - 0 \right)\hat{\mathbf{j}} + \left( 0 - 2 \right)\hat{\mathbf{k}} = \langle 1, 0, -2 \rangle$
The Projection Trick:
Calculating integrals over curved 3D surfaces ($dS$) is incredibly difficult. We use a trick to project the curved surface down onto its flat 2D “shadow” in the xy-plane ($dA$). For any surface defined by $z = g(x,y)$, we rewrite it as a level surface $f(x,y,z) = z - g(x,y) = 0$.
The upward-pointing normal vector $\vec{N}$ is the gradient: $\nabla f = \langle -g_x, -g_y, 1 \rangle$.
Normal vector $\hat{\mathbf{n}}$ to the surface. The surface $S$ is given by $z = 4 -x^2-y^2$. The normal vector to the surface can be found by computing the gradient of the scalar function $f(x, y, z)$ (it represents how f changes in each direction) $= z -(4 -x^2-y^2) = z -4 + x^2 + y^2$
If we define the surface implicitly, $\nabla f = \langle \frac{\partial f}{\partial x}, \frac{\partial f}{\partial y}, \frac{\partial f}{\partial z}\rangle = \langle 2x, 2y, 1\rangle$. This is the normal vector, but we should normalize it to get the unit normal vector. However, we don’t need to normalize this vector since we’re only interested in the direction for the surface integral.
If instead we define the surface explicitly: $z = g(x, y) = 4 - x^2 - y^2$. $\nabla f = \langle -g_x, -g_y, 1 \rangle = \langle -(-2x), -(-2y), 1 \rangle = \langle 2x, 2y, 1\rangle$
When we project to the flat shadow area $dA$, the math requires us to use the unit normal $\hat{\mathbf{n}} = \frac{\vec{N}}{\Vert{}\vec{N}\Vert{}}$ but simultaneously scale the area element $dS = \Vert{}\vec{N}\Vert{} dA$.
Notice what happens: $\hat{\mathbf{n}} \, dS = \left(\frac{\vec{N}}{\Vert{}\vec{N}\Vert{}}\right) \Vert{}\vec{N}\Vert{} \, dA = \vec{N} \, dA$. The magnitudes perfectly cancel out! We can bypass $dS$ entirely and just use the unnormalized gradient vector $\vec{N}$ directly with the flat area element $dA$.
Compute the Surface integral. $(\nabla \times \vec{F})\hat{\mathbf{n}} = \langle 1, 0, -2\rangle \langle 2x, 2y, 1\rangle = 2x -2.$
Our surface integral is now projected onto the flat shadow region $D$ (the circle $x^2 + y^2 \leq 1$):
$\int \int_{S} (\nabla \times \vec{F})\hat{\mathbf{n}}dS = \int \int_{D} (2x-2)dA$.
Switching to polar coordinates, where $x = r\cos(\theta)$ and $y = r\sin(\theta), dA = rdr d\theta$. The bounds for $r$ are from $0$ to $1$, and for $\theta$ from $0$ to $2\pi$.
$=\int_{S} (2x-2)dA = \int_{0}^{2\pi}\int_{0}^{1} (2 r\cos(\theta)-2)rdr d\theta = \int_{0}^{2\pi}\int_{0}^{1} (2r^2\cos( \theta)-2r)dr d\theta$
Evaluate the inner integral with respect to r: $\int_{0}^{1} 2r^2\cos( \theta)dr = 2\cos( \theta)\frac{r^3}{3}\bigg|_{0}^{1} = 2\cos( \theta)\frac{1}{3} = \frac{2}{3}\cos( \theta)$
$\int_{0}^{1} -2rdr = -r^2\bigg|_{0}^{1}=-1$
So the surface integral becomes: $\int_{0}^{2\pi} (\frac{2}{3}\cos( \theta)-1) d\theta$
Separate and evaluate each term:
$\frac{2}{3}\int_{0}^{2\pi} cos( \theta) d\theta = \frac{2}{3} 0 = 0$
$\int_{0}^{2\pi} -1 d\theta = - \theta\bigg|_{0}^{2\pi} = -2\pi$
So the surface integral is: $\int \int_{S} (\nabla \times \vec{F})·\hat{\mathbf{n}}dS = -2\pi$
Conclusion: Both the surface integral and the line integral yield the same result, confirming Stokes’ Theorem.

Calculating this line integral directly would require parameterizing three separate 3D line segments. Instead, we can use Stokes’ Theorem, which equates the circulation around the boundary to the flux of the curl through the triangular surface $S$:
$$\oint_C \vec{F} \cdot d\vec{r} = \iint_{S} (\nabla \times \vec{F}) \cdot \hat{\mathbf{n}} \, dS$$Step 1: Calculate the Curl. $\operatorname{curl}(\vec{F}) = \nabla \times \vec{F} = \begin{vmatrix} \hat{\mathbf{i}} & \hat{\mathbf{j}} & \hat{\mathbf{k}} \\ \frac{\partial}{\partial x} & \frac{\partial}{\partial y} & \frac{\partial}{\partial z} \\ z^2 & y^2 & x \end{vmatrix}$
$\operatorname{curl}(\vec{F}) = (\frac{\partial R}{\partial y}-\frac{\partial Q}{\partial z})\hat{\mathbf{i}}-(\frac{\partial R}{\partial x}-\frac{\partial P}{\partial z})\hat{\mathbf{j}} + (\frac{\partial Q}{\partial x}-\frac{\partial P}{\partial y})\hat{\mathbf{k}} = (0-0)\hat{\mathbf{i}}-(1-2z)\hat{\mathbf{j}}+(0-0)\hat{\mathbf{k}} = (2z -1)\hat{\mathbf{j}} = \langle 0, 2z -1, 0 \rangle$ where $P = z^2, Q = y^2$, and $R = x$.
Step 2: Define the Surface and Normal Vector
The surface $S$ is a flat triangle with vertices at $(1, 0, 0), (0, 1, 0)$, and $(0, 0, 1)$. The equation of the plane that contains these points is: $x + y + z = 1$.
Finding the Plane Equation: Let $P=(1,0,0)$, $Q=(0,1,0)$, and $R=(0,0,1)$. We form two vectors in the plane:$\vec{PQ} = \langle -1, 1, 0 \rangle$ and $\vec{PR} = \langle -1, 0, 1 \rangle$. Taking their cross product yields the normal vector to the plane:$\vec{N} = \vec{PQ} \times \vec{PR} = \langle 1, 1, 1 \rangle$. Using the point-normal equation $1(x-1) + 1(y-0) + 1(z-0) = 0$, we find the plane equation is exactly $x + y + z = 1$.
We can express this surface as a function of $x$ and $y$: $z = g(x, y) = 1 - x - y$. To calculate the surface integral, we project the tilted 3D triangle onto the flat 2D $xy$-plane. The differential surface area vector is defined by the gradient projection formula: $d\vec{S} = \hat{\mathbf{n}} \, dS = \langle -g_x, -g_y, 1 \rangle dx\,dy$.
Because $g_x = -1$ and $g_y = -1$: $d\vec{S} = \langle 1, 1, 1 \rangle dx\,dy$
This normal vector is constant across the surface and does not require normalization because Stokes’ Theorem only requires the direction of the normal vector.
Step 3: Evaluate the Surface Integral
Since the surface $S$ is defined by the triangle in the plane $x +y +z = 1$, we can project this triangle onto the $xy$-plane. The projection is a triangular region $D$ (we plug $z = 0$ into the equation of the plane) $x +y \leq 1$, bounded by $0 \leq x \leq 1$, and given a fixed $x, y$ ranges from $0$ to $1 -x$.
We take the dot product of the curl and our differential surface vector:
$\int \int_{S} (\nabla \times \vec{F}) \cdot \hat{\mathbf{n}}dS = \int \int_{D} \langle 0, 2z -1, 0 \rangle \cdot \langle 1, 1, 1\rangle dA = \int_{0}^{1} \int_{0}^{-x+1} (2z -1)dydx$
We must substitute out the $z$ variable using our plane equation $z = 1 - x - y$: $\int_{0}^{1} \int_{0}^{-x+1} [2(1-x-y)-1]dydx = \int_{0}^{1} \int_{0}^{-x+1} (1-2x-2y)dydx$
Compute the Double Integral
Evaluate the inner integral with respect to $y$: $\int_{0}^{1-x} (1 - 2x - 2y) \, dy = \left[ y - 2xy - y^2 \right]_{0}^{1-x}$
$(-x+1)-2(-x+1)x-(-x+1)^2 = -x +1 + 2x^2-2x-(x^2+1-2x) = -x +1 + 2x^2-2x-x^2-1+2x = x^2-x $
Evaluate the outer integral with respect to $x$: $\int_{0}^{1} (x^2-x)dx = \frac{x^3}{3}-\frac{x^2}{2}\bigg|_{0}^{1} = \frac{1}{3}-\frac{1}{2} = -\frac{1}{6}$
Conclusion. Thus, the value of the line integral is: $\oint_C \vec{F} \cdot d\vec{r} = -\frac{1}{6}$
Green’s Theorem is a fundamental pillar of 2D calculus.
Green’s Theorem. If $C$ is a positively oriented (counterclockwise) simple closed curve enclosing a flat region $R$, and $\vec{F} = \langle P(x, y), Q(x,y) \rangle$ is a vector field that is defined and has continuous partial derivatives on an open region containing $R$, then Green's Theorem states that: $\oint_C \vec{F} \cdot{} d\vec{r} = \iint_R \operatorname{curl}(\vec{F}) dA$. Equivalently, $\oint_C Pdx + Qdy = \iint_R (Q_x-P_y)dA = \iint_R (\frac{\partial Q}{\partial x}-\frac{\partial P}{\partial y})dA$ where
Stokes’ Theorem generalizes Green’s Theorem to three dimensions. Green’s Theorem restricts you to a flat sheet of paper (the $xy$-plane). Stokes’ Theorem allows that paper to be stretched, folded, or ballooned into any arbitrary 3D surface, provided the boundary curve remains intact.
Given a vector field $\vec{F}$, a smooth surface $S$, and a simple, closed curve $C$ that forms the boundary of the surface $S$, Stokes’ Theorem asserts that: $\oint_C \vec{F} \cdot d\vec{r} = \int \int_{S} (\nabla \times \vec{F}) \cdot \hat{\mathbf{n}}dS$
To see how Stokes’ Theorem generalizes Green’s Theorem, let’s assume that the curve $C$ lies in the $xy$-plane and is oriented counter-clockwise. We choose a surface $S$ that is bounded by the curve $C$ (Figure iii). In this particular case, the unit normal vector $\hat{\mathbf{n}}$ to the surface is $\hat{\mathbf{k}}$, which is the unit vector in the $z$-direction.
Let’s apply Stokes’ Theorem: $\oint_C \vec{F} \cdot d\vec{r} = \iint_{S} (\nabla \times \vec{F}) \cdot \hat{\mathbf{n}} \, dS$
$\oint_C P\,dx + Q\,dy = \iint_{S} (\nabla \times \vec{F}) \cdot \hat{\mathbf{k}} \, dx\,dy$
Notice that taking the dot product with $\hat{\mathbf{k}}$ simply extracts the $z$-component of the curl. $\nabla \times \vec{F} = \langle \dots, \dots, \frac{\partial Q}{\partial x} - \frac{\partial P}{\partial y} \rangle$. Hence, $(\nabla \times \vec{F}) \cdot \hat{\mathbf{k}} = \frac{\partial Q}{\partial x} - \frac{\partial P}{\partial y}$.
Substituting this back into the surface integral yields: $\boxed{\oint_C P\,dx + Q\,dy = \iint_S \left( \frac{\partial Q}{\partial x} - \frac{\partial P}{\partial y} \right) dA}$ This is exactly Green’s Theorem! Stokes’ theorem is indeed a generalization of Green’s theorem to higher dimensions. Green’s Theorem is restricted to two-dimensional regions in the plane (e.g., $xy$-plane), while Stokes’ Theorem applies to any surface in $\mathbb{R}^3$ bounded by a closed curve.
While a rigorous algebraic proof of Stokes’ Theorem for arbitrary curved surfaces is highly complex, the geometric intuition behind it is surprisingly simple and beautiful.
Stokes’ Theorem. Given a vector field $\vec{F}$, a smooth surface $S$, and a simple, closed curve $C$ that forms the boundary of the surface $S$, it asserts that: $\oint_C \vec{F} \cdot d\vec{r} = \int \int_{S} (\nabla \times \vec{F})·\hat{\mathbf{n}}dS$
Proof
🧩 Special Case: The XY-Plane
To start, let’s prove Stokes’ Theorem for the special case where the curve $C$ and surface $S$ lie in the $xy$-plane. In this case, Stokes’ Theorem reduces to Green’s Theorem. Here’s how:
Thus, the line integral around C becomes: $\oint_C \vec{F} \cdot d\vec{r} = \oint_C Pdx + Qdy$.
This is exactly the line integral appearing in Green’s Theorem. Green’s Theorem states: $\oint_C Pdx + Qdy = \int \int_{S} (Q_x-P_y)dxdy$
So we already have: $\oint_C \vec{F} \cdot d\vec{r} = \int \int_{S} (\frac{\partial Q}{\partial x}-\frac{\partial P}{\partial y})dA$.
Notice that the integrand in Green’s Theorem is the z-component of the curl of $\vec{F}$, which is: $\operatorname{curl}(\vec{F}) = \nabla \times \vec{F} = (\frac{\partial R}{\partial y}-\frac{\partial Q}{\partial z})\hat{\mathbf{i}}-(\frac{\partial R}{\partial x}-\frac{\partial P}{\partial z})\hat{\mathbf{j}} + (\frac{\partial Q}{\partial x}-\frac{\partial P}{\partial y})\hat{\mathbf{k}}$
Stokes’ Theorem states that $\oint_C \vec F \cdot d\vec r = \iint_S (\nabla \times \vec F)\cdot \hat{\mathbf{n}}\,dS.$
But here:
So: $\iint_S (\nabla \times \vec F)\cdot \hat{\mathbf{k}}\,dS = \iint_S (Q_x - P_y)\,dx\,dy.$
Thus, $\oint_C \vec F \cdot d\vec r = \iint_S (Q_x - P_y)\,dx\,dy.$ which is exactly Green’s Theorem.
🧩 General Surface S
🌄 The Big Picture. Stokes’ Theorem for a general surface is nothing more than this: apply the planar version of Stokes (i.e., Green’s Theorem) to tiny flat pieces, then let the interior edges cancel.
Now, let’s move to the more general case where $S$ is any arbitrary smooth surface $S$ with a boundary curve $C$ in three-dimensional space, not restricted to the $xy$-plane.
To prove Stokes’ Theorem for a general surface, the key🔑 idea is to divide or decompose the surface $S$ into many infinitesimal (very small), nearly flat pieces, similar to a mosaic or mesh (Figure A). This technique allows us to approximate each small piece as a flat surface, so Stokes' Theorem can be applied locally to each piece.
Step 1. Partition the surface. Suppose the surface $S$ is divided into many small surface elements (tiny pieces) $S_i$, each with a small boundary curve $C_i$. $S = \cup_i S_i$ These infinitesimal elements can be considered nearly flat, making it possible to apply Stokes’ Theorem locally.
Step 2. Apply Stokes’ Theorem locally. For each tiny surface element $S_i$, each enclosed by a microscopic boundary curve $C_i$, by the planar case (Green’s Theorem), the line integral around the small boundary $C_i$ is equal to the flux of the curl through the corresponding surface element $S_i$: $\oint_{C_i} \vec{F} \cdot d\vec{r} = \int \int_{S_i} (\nabla \times \vec{F})\cdot \hat{\mathbf{n_i}}dS$ where $\hat{\mathbf{n_i}}$ is the unit normal vector to the surface element $S_i$.
Because each patch is nearly flat, you can apply the planar version of Stokes’ Theorem to each one.

Step 3. Next, sum the contributions from all these small elements or pieces. The total line integral around the boundary of the entire surface $S$ is the sum of the line integrals around each small boundary $C_i$: $\oint_{C} \vec{F} \cdot d\vec{r} = \sum_{i} \oint_{C_i} \vec{F} \cdot d\vec{r}$
Similarly, the total flux of the curl of $\vec{F}$ through the surface $S$ is the sum of the fluxes through each small surface element or piece $S_i$: $\int \int_{S} (\nabla \times \vec{F}) \cdot \hat{\mathbf{n}}dS = \sum_{i} \int \int_{S_i} (\nabla \times \vec{F}) \cdot \hat{\mathbf{n_i}}dS$.
$$\sum_{i} \oint_{C_i} \vec{F} \cdot d\vec{r} = \sum_{i} \iint_{S_i} (\nabla \times \vec{F}) \cdot \hat{\mathbf{n}}_i \, dS$$The right side of this equation is simply the definition of the macroscopic surface integral over the whole surface: $\iint_S (\nabla \times \vec{F}) \cdot \hat{\mathbf{n}} \, dS$. But what happens to the left side?
Step 4. The Canceling Borders (The Gear Analogy) As we sum all the tiny boundary line integrals $\oint_{C_i} \vec{F} \cdot d\vec{r}$, a miraculous cancellation occurs.
Imagine a grid of closely packed, identically spinning gears. Where two gears touch (an interior border), their teeth are moving in exactly opposite directions. The math works exactly the same way. For any two adjacent patches on the surface, the shared interior boundary curve is traversed in opposite directions by each patch.
When you sum them up, every single interior boundary perfectly cancels out to zero.
🎉 The only line integrals that survive this mass cancellation are those on the extreme outer edge of the surface, because they have no neighboring patch to cancel them. Therefore, the sum of all microscopic boundary integrals perfectly collapses into the single, macroscopic line integral around the outer boundary $C$.
$$\oint_{C} \vec{F} \cdot d\vec{r} = \iint_{S} (\nabla \times \vec{F}) \cdot \hat{\mathbf{n}} \, dS$$This geometric logic proves that the total curl flux through the surface is indistinguishable from the fluid circulation around its outer rim.
Therefore, Stokes’ Theorem holds true as the line integral around the boundary $C$ is equal to the flux of the curl through the entire surface $S$, regardless of the shape or orientation of $S$. The total microscopic rotation inside a surface equals the macroscopic rotation around its boundary.

JustToThePoint Copyright © 2011 - 2026 Anawim. ALL RIGHTS RESERVED. Bilingual e-books, articles, and videos to help your child and your entire family succeed, develop a healthy lifestyle, and have a lot of fun. Social Issues, Join us.
This website uses cookies to improve your navigation experience.
By continuing, you are consenting to our
use of cookies, in accordance with our Cookies Policy and
Website Terms and Conditions of use.