
|
 |

|
|
|
|
|
|
The excitement of learning separates youth from old age. As long as you’re learning, you’re not old, Rosalyn S.Yalow.

Definition. A vector $\vec{AB}$ is a geometric object or quantity that has both magnitude (or length) and direction. Vectors in an n-dimensional Euclidean space can be represented as coordinates vectors in a Cartesian coordinate system.
Definition. The magnitude of the vector $\vec{A}$, also known as length or norm, is given by the square root of the sum of its components squared, $|\vec{A}|~ or~ ||\vec{A}|| = \sqrt{a_1^2+a_2^2+a_3^2}$, e.g., $\vert{}\vert{}\langle 3, 2, 1 \rangle\vert{}\vert{} = \sqrt{3^2+2^2+1^2} = \sqrt{14}$, $\vert{}\vert{}\langle 3, -4, 5 \rangle\vert{}\vert{} = \sqrt{3^2+(-4)^2+5^2} = \sqrt{50} = 5\sqrt{2}$, or $\vert{}\vert{}\langle 1, 0, 0 \rangle\vert{}\vert{} = \sqrt{1^2+0^2+0^2} = \sqrt{1} = 1$.
Vector Addition: The sum of two vectors is the sum of their components, $\vec{A}+ \vec{B} = (a_1+b_1)\vec{i}+(a_2+b_2)\vec{j}+(a_3+b_3)\vec{k} = \langle a_1+b_1, a_2+b_2, a_3+b_3 \rangle$.
Vector Subtraction: The subtraction of two vectors is similar to addition and is also done component-wise, it is given by simply subtracting their corresponding components (x, y, and z in 3D), $\vec{A} - \vec{B} = (a_1-b_1)\vec{i}+(a_2-b_2)\vec{j}+(a_3-b_3)\vec{k} = \langle a_1-b_1, a_2-b_2, a_3-b_3 \rangle$.
Scalar multiplication is the multiplication of a vector by a scalar, a real number, changing its magnitude without altering its direction (unless the scalar is negative, which reverses the direction). It is effectively multiplying each component of the vector by the scalar value, $c\vec{A} = (ca_1)\vec{i}+(ca_2)\vec{j}+(ca_3)\vec{k} = \langle ca_1, ca_2, ca_3 \rangle$.
The dot or scalar product is a fundamental operation between two vectors. It produces a scalar quantity that represents the projection of one vector onto another. The dot product is the sum of the products of their corresponding components: $\vec{A}·\vec{B} = \sum a_ib_i = a_1b_1 + a_2b_2 + a_3b_3.$, e.g. $\vec{A}·\vec{B} = \sum a_ib_i = \langle 2, 2, -1 \rangle \cdot \langle 5, -3, 2 \rangle = (2 \cdot 5) + (2 \cdot -3) + (-1 \cdot 2) = 10 - 6 - 2 = 2.$
Geometrically, it is the product of their magnitudes multiplied by the cosine of the angle $\theta$ between them, $\boxed{\vec{A} \cdot \vec{B} = \vert{}\vert{}\vec{A}\vert{}\vert{} \cdot \vert{}\vert{}\vec{B}\vert{}\vert{} \cos(\theta)}$
The projection of $\vec{a}$ onto $\vec{b}$ is $proj_{\vec{b}}\vec{a} = \frac{\vec{a}·\vec{b}}{||\vec{b}||^2}\vec{b}$.
The cross product, denoted by $\vec{A} \times \vec{B}$, is a binary operation on two vectors in three-dimensional space. It yields a new vector that is perpendicular (orthogonal, at a right angle) to both original vectors and has a magnitude equal to the area of the parallelogram formed by the two input vectors.
The cross product $\vec{A}x\vec{B}$ can be computed using the determinant of a $3 \times 3$ matrix formed by the standard basis vectors ($\hat{\mathbf{i}}, \hat{\mathbf{j}}, \hat{\mathbf{k}}$) and the components of the two vectors: $\vec{A} \times \vec{B} = det(\begin{smallmatrix} \hat{\mathbf{i}} & \hat{\mathbf{j}} & \hat{\mathbf{k}} \\\ a_1 & a_2 & a_3\\\ b_1 & b_2 & b_3\end{smallmatrix}) =|\begin{smallmatrix}a_2 & a_3\\\ b_2 & b_3\end{smallmatrix}|\vec{i}-|\begin{smallmatrix}a_1 & a_3\\\ b_1 & b_3\end{smallmatrix}|\vec{j}+|\begin{smallmatrix}a_1 & a_2\\\ b_1 & b_2\end{smallmatrix}|\vec{k}$.
Example: If $\vec{A} = \langle 1, 2, 3 \rangle$ and $\vec{B} = \langle 4, 5, 6 \rangle$: $\vec{A} \times \vec{B} = \begin{vmatrix} \hat{\mathbf{i}} & \hat{\mathbf{j}} & \hat{\mathbf{k}} \\ 1 & 2 & 3 \\ 4 & 5 & 6 \end{vmatrix} = (2\cdot 6 - 3\cdot 5)\hat{\mathbf{i}} - (1\cdot 6 - 3\cdot 4)\hat{\mathbf{j}} + (1\cdot 5 - 2\cdot 4)\hat{\mathbf{k}} = -3\hat{\mathbf{i}} + 6\hat{\mathbf{j}} - 3\hat{\mathbf{k}} = \langle -3, 6, -3 \rangle$
Matrices offers an efficient way for solving systems of linear equations. Utilizing matrices, we can represent these equations more concisely and conveniently. For instance, consider the system of equations:
$\begin{cases} x + y + z = 7 \\ 3x -2y -z = 4 \\ x + 6y + 5z = 24 \end{cases}$
This can be written in matrix form as: A · X = U where: $A = \bigr(\begin{smallmatrix}1 & 1 & 1\\\ 3 & -2 & -1\\\ 1 & 6 & 5\end{smallmatrix}\bigl), X = \bigr(\begin{smallmatrix}x_1\\ x_2\\ x_3\end{smallmatrix}\bigl), B = \bigr(\begin{smallmatrix}7\\\ 4\\\ 24\end{smallmatrix}\bigl)$.
A system of $n$ linear equations with $n$ variables can be written in matrix form as $AX = B$:
For a square matrix $A$ over a field (such as $\mathbb{R}$ or $\mathbb{C}$):
The matrix inverse $A^{-1}$ is calculated as: $\boxed{A^{-1} = \frac{1}{\det(A)} \operatorname{adj}(A)}$ where $\operatorname{adj}(A) = C^T$ is the adjugate matrix (the transpose of the cofactor matrix $C$). The cofactor elements are $C_{ij} = (-1)^{i+j} M_{ij}$, where $M_{ij}$ is the determinant of the $(n-1) \times (n-1)$ submatrix formed by removing both the row $i$ and the column $j$.


Create a Table of Values:
| t | x | y |
|---|---|---|
| -3 | -8 | -7 |
| -2 | -5 | -2 |
| -1 | -2 | 1 |
| 0 | 1 | 2 |
| 1 | 4 | 1 |
| 2 | 7 | -2 |
| 3 | 10 | -7 |
Solve for t in the first equation (i), $t = \frac{x-1}{3}$, and substitute into the second equation (ii) $y = 2 -t^2 = 2 -(\frac{(x-1)}{3})^2 ⇒y = \frac{-1}{9}(x-1)^2+2$. As t increases, x increases and y first increases to a maximum 2 (t = 0, (x, y) = (1, 2)) and then decreases.
The Cartesian equation is a parabola: $y = a(x -h)^2 + k$, where the vertex is (h, k). In this example, the vertex is (1, 2). The coefficient $\frac{-1}{9}$ indicates the parabola opens downwards and is vertically compressed.
Solve each equation for the trigonometric function. $x = 4\cos(\theta)$, $\quad y = 3\sin(\theta)$, $\quad -\frac{\pi}{2} \le \theta \le \frac{\pi}{2}$
Isolate and Substitute $\cos(t)$ and $\sin(t)$ from the above equations and use the Pythagorean identity: $\sin^2(\theta)+cos^2(\theta) = 1 \implies \frac{x^2}{16}+\frac{y^2}{9} = 1.$
Analysis: This is the equation of an ellipse with center at the origin (0, 0). The semi-major axis is 4 (along the x-axis) and the semi-minor axis is 3 (along the y-axis). However, because the domain is restricted to $[-\pi/2, \pi/2]$, $\cos(\theta)$ is always positive, meaning $x \ge 0$. We are only looking at the right half of the ellipse.
Direction of Motion: This movement is in the counter-clockwise direction, starting from the bottom point (0, −3), moving through (4, 0), and ending at (0, 3).
| t | x | y |
|---|---|---|
| $-\pi/2$ | 0 | -3 |
| 0 | 4 | 0 |
| $\pi/2$ | 0 | 3 |
A cycloid is the path traced by a specific point P on the rim of a wheel with radius a, as it rolls along a straight line (the x axis) without slipping. P is a point on the rim of a wheel, and it starts at the origin (0, 0).
To describe the cycloid, we need to express the coordinates x and y of point P as functions of the angle $\theta$ by which the wheel has rotated. Refer to Figures ii and iii in the diagram for a visual aid.
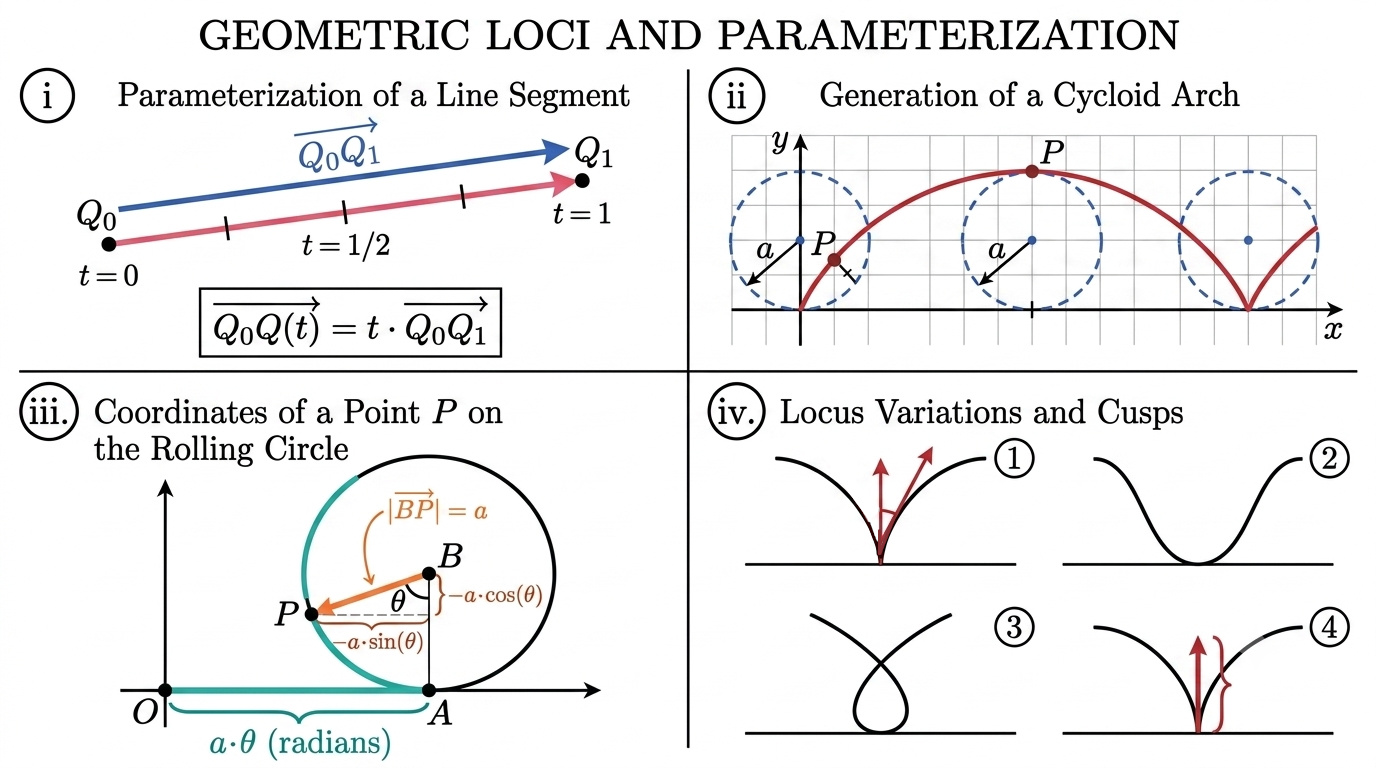
Let the center of the wheel be C. As the wheel rolls horizontally, the center O of the wheel moves horizontally. $\vec{OP}$ represents the distance traveled by the wheel’s center O.
$\vec{OP} = \vec{OA} + \vec{AB} + \vec{BP}$ where: (i) $\vec{OA}$ is equal to the Arc length from A to P, $\vec{OA} = \langle \theta \cdot a , 0\rangle$ is (provided the angle θ is expressed in radians and the wheel is not slipping) the amount by which the wheel has rolled or moved horizontally. (ii) $\vec{AB}$ represents the vertical distance from the center of the wheel to the point A, that is, $\langle 0, a\rangle$ (the center’s height remains a constant). (iii) $\vec{BP}$ represents the position of point P relative to the center of the wheel after it has rotated by an angle $\theta$, $\vec{BP} = \langle -a\cdot \sin(\theta), -a\cdot \cos(\theta) \rangle$.
Therefore, $\vec{OP} = \vec{OA} + \vec{AB} + \vec{BP} = \langle \theta -a\sin(\theta), a - a\cos(\theta)⟩.$
Thus, the parametric equations for the cycloid are:
$\begin{cases} x(\theta) = a\theta -a\sin(\theta)\\ y(\theta) = a - a\cos(\theta) \end{cases}$
To understand how the curve behaves just as it lifts off the ground, we can analyze the slope of the tangent line near $\theta = 0$. Let’s set $a = 1$ to simplify: (Figure iv)
Parametric Equations Simplified:
$\begin{cases} x(\theta) = \theta -\sin(\theta)\\ y(\theta) = 1 - \cos(\theta) \end{cases}$
Using Maclaurin (Taylor) series approximations for small $\theta$: $\cos(\theta) \approx 1 - \frac{\theta^2}{2}$, $\sin(\theta) \approx \theta - \frac{\theta^3}{6}$, we drop the cubic term $- \frac{\theta^3}{6}$ because for very small $\theta$, the linear term $\theta$ dominates, and the cubic term is much smaller in magnitude.
Substituting these into our derivatives to find the tangent slope $dy/dx$: $\frac{dy}{d\theta} = \sin(\theta) \approx \theta$, $\frac{dx}{d\theta} = 1 - \cos(\theta) \approx \frac{\theta^2}{2}$
The slope of the curve is the ratio of these derivatives: $\frac{dy}{dx} = \frac{dy/d\theta}{dx/d\theta} \approx \frac{\theta}{\theta^2/2} = \frac{2}{\theta}$
As $\theta$ approaches zero, the slope $\frac{2}{\theta}$ approaches infinity. This confirms that the cycloid has a vertical tangent line exactly at the points where it touches the x-axis, creating the sharp “cusps” characteristic of the curve, as shown in Figure iv, sketch 4.

JustToThePoint Copyright © 2011 - 2026 Anawim. ALL RIGHTS RESERVED. Bilingual e-books, articles, and videos to help your child and your entire family succeed, develop a healthy lifestyle, and have a lot of fun. Social Issues, Join us.
This website uses cookies to improve your navigation experience.
By continuing, you are consenting to our
use of cookies, in accordance with our Cookies Policy and
Website Terms and Conditions of use.