
|
 |

|
|
|
|
|
|
For every problem there is always, at least, a solution which seems quite plausible. It is simple and clean, direct, neat and nice, and yet very wrong, #Anawim, justtothepoint.com
A vector field is an assignment of a vector $\vec{F}$ to each point $(x, y)$ in the plane. In two dimensions, this is written or expressed as $\vec{F}(x,y) = P(x,y)\hat{\mathbf{i}} + Q(x,y)\hat{\mathbf{j}}$, where $P$ and $Q$ are scalar functions of $x$ and $y$, and $\hat{\mathbf{i}}$ and $\hat{\mathbf{j}}$ are the standard unit vectors.
A vector field on a plane can be visualized as a continuous collection of arrows, each attached to a specific coordinate point on the plane. These arrows represent vectors with specific magnitudes and directions.
In physics, work is defined as the energy transferred when a force acts upon an object, causing a displacement. If the force is constant and the path is a straight line, work is simply the dot product of force and displacement ($W = \vec{F} \cdot \vec{d}$).
However, what if the path is curved and the force changes at every point in space? We must use a line integral. The work done by a force field $\vec{F}$ moving an object along a trajectory $C$ is defined as: $W = \int_{C} \vec{F} \cdot d\vec{r} = \int_{C} (P dx + Q dy)$
Alternatively, we can express this using the unit tangent vector $\hat{\mathbf{T}}$ and arc length $s$: $W = \int_{C} \vec{F} \cdot \hat{\mathbf{T}} ds$
The Intuition: The dot product $\vec{F} \cdot d\vec{r}$ isolates the component of the force vector that points exactly in the direction of the curve at that specific microscopic instant. Forces pushing perpendicular to your motion do zero work!
A vector field is conservative if there exists a scalar function $f$ such that $\vec{F} = \nabla f$. This means the vector field is exactly the gradient of some underlying scalar field $f$. This scalar function is known or referred to as the potential function associated with the vector field.
Theorem. The Fundamental Theorem of Calculus for Line Integral. If $\vec{F}$ is a conservative vector field in a simply connected region of space (i.e., a region with no holes), and if $f$ is a scalar potential function for $\vec{F}$ in that region, then the work done moving from point $P_0$ to point $P_1$ is entirely independent of the path taken. Indeed, it depends only on the endpoints: $\int_{C} \vec{F}\cdot d\vec{r} = \int_{C} \nabla f\cdot d\vec{r} = f(P_1)-f(P_0)$ where $P_0$ and $P_1$ are the initial and final points of the curve $C$, respectively.
A line integral in space extends these concepts to three dimensions, allowing us to integrate a function along a 3D curve. This mathematical tool is the backbone of advanced physics, used to calculate:
Consider a vector field $\vec{F}$ in three dimensional space. A vector field can be expressed as: $\vec{F} = P\hat{\mathbf{i}} + Q\hat{\mathbf{j}}+R\hat{\mathbf{k}}$ where $P$, $Q$, and $R$ are functions of the coordinates $x, y$, and $z$ respectively. Each of these functions represents the components of the vector field in the $\hat{\mathbf{i}}$ ($x$-axis), $\hat{\mathbf{j}}$ ($y$-axis), and $\hat{\mathbf{k}}$ ($z$-axis) directions, respectively.
The vector field $\vec{F}$ can represent various physical phenomena where a vector quantity is defined at every point in space, such as:
To perform a line integral, we first need to describe the curve $C$ along which we are integrating. A curve in three dimensions can be parametrized by a parameter $t$ (often representing time), which varies over an interval $[a, b]$. The curve is represented as: $\vec{r}(t)=\langle x(t), y(t), z(t)\rangle $ where $a \leq t \leq b$. The functions $x(t), y(t)$, and $z(t)$ are the coordinates that describe the positions of points on the curve $C$ as the parameter $t$ varies from $a$ to $b$.
The line integral of the vector field $\vec{F}$ along the curve $C$ is defined as: $\int_{C} \vec{F} \cdot d\vec{r}$ where $d\vec{r}$ represents an infinitesimal vector (small step) strictly tangent to the curve at each point. The vector $d\vec{r}$ can be expressed as: $d\vec{r} = \langle dx, dy, dz\rangle $.
In the context of physics, when the vector field represents a force, the line integral of the vector field along a curve $C$ gives the work done by the force as it moves a particle along the curve.
To compute the line integral, we express $d\vec{r}$ in terms of the parameter $t$. Given the parametrization $\vec{r}(t)=\langle x(t), y(t), z(t)\rangle $, the differential vector $d\vec{r}$ can be written as: $d\vec{r} = \frac{d\vec{r}}{dt}dt = \langle \frac{dx}{dt}, \frac{dy}{dt}, \frac{dz}{dt}\rangle dt$.
Now, substituting $d\vec{r}$ into the line integral expression: $\int_{C} \vec{F} \cdot d\vec{r} = \int_{a}^{b} \vec{F}(\vec{r}(t)) \cdot \frac{d\vec{r}}{dt}dt$
Given the vector field $\vec{F} = P\hat{\mathbf{i}} + Q\hat{\mathbf{j}}+R\hat{\mathbf{k}}$, we can express it as: $\vec{F}(\vec{r}(t)) = \langle P(x(t), y(t), z(t)), Q(x(t), y(t), z(t)), R(x(t), y(t), z(t))\rangle $
Thus, the dot product $\vec{F} \cdot d\vec{r}$ becomes, $\vec{F} \cdot d\vec{r} = \langle P, Q, R \rangle \cdot \left\langle \frac{dx}{dt}, \frac{dy}{dt}, \frac{dz}{dt} \right\rangle dt = \left( P \frac{dx}{dt} + Q \frac{dy}{dt} + R \frac{dz}{dt} \right) dt$
Substituting this into the line integral gives: $\int_{C} \vec{F} \cdot d\vec{r} = \int_{a}^{b} (P\frac{dx}{dt} + Q\frac{dy}{dt} + R\frac{dz}{dt})dt = \int_{a}^{b} (P(x(t), y(t), z(t))\frac{dx}{dt} + Q(x(t), y(t), z(t))\frac{dy}{dt} + R(x(t), y(t), z(t))\frac{dz}{dt})dt$
Conclusion: Given a vector field $\vec{F} = \langle P(x, y, z), Q(x, y, z), R(x, y, z)\rangle $ and a curve $C$ parametrized by $\vec{r}(t)=\langle x(t), y(t), z(t)\rangle $, the line integral is defined as: $\int_{C} \vec{F} \cdot d\vec{r} = \int_{a}^{b} (P\frac{dx}{dt} + Q\frac{dy}{dt} + R\frac{dz}{dt})dt = \int_{a}^{b} (P(x(t), y(t), z(t))\frac{dx}{dt} + Q(x(t), y(t), z(t))\frac{dy}{dt} + R(x(t), y(t), z(t))\frac{dz}{dt})dt$
The curl of a vector field measures the tendency of the field to induce microscopic rotation or “twisting” at a specific point in space. Just as the divergence measures how much a field expands or compresses, the curl measures how much it twists. Furthermore, evaluating the curl is the ultimate test to determine if a vector field is conservative.
Definition. Given a vector field $\vec{F} = P\hat{\mathbf{i}}+ Q\hat{\mathbf{j}}+R\hat{\mathbf{k}}$ where $P, Q$, and $R$ are continuous, differentiable scalar functions representing the components of the field along the $x$-, $y$-, and $z$-directions, respectively, the curl of $\vec{F}$ is defined as the cross product of the del operator ($\nabla$) with the vector field. $\operatorname{curl}(\vec{F}) = \nabla \times \vec{F} = \begin{vmatrix} \hat{\mathbf{i}} & \hat{\mathbf{j}} & \hat{\mathbf{k}} \\ \frac{\partial}{\partial x} & \frac{\partial}{\partial y} & \frac{\partial}{\partial z} \\ P & Q & R \end{vmatrix}$
Expanding this determinant yields the formal algebraic definition: $\operatorname{curl}(\vec{F}) = \left( \frac{\partial R}{\partial y} - \frac{\partial Q}{\partial z} \right)\hat{\mathbf{i}} - \left( \frac{\partial R}{\partial x} - \frac{\partial P}{\partial z} \right)\hat{\mathbf{j}} + \left( \frac{\partial Q}{\partial x} - \frac{\partial P}{\partial y} \right)\hat{\mathbf{k}}$
By construction, if the vector field $\vec{F}$ is defined in a simply connected region (a region without topological holes or infinite tunnels), then $\vec{F}$ is conservative (meaning it can be expressed as the gradient of a scalar function, $\vec{F}= \nabla f$ where $\nabla$ is the gradient operator) if and only if its curl is everywhere equal to the zero vector, $\operatorname{curl}(\vec{F}) = \nabla \times \vec{F} = 0$.
When the curl vanishes, there is no rotational component in the field, guaranteeing that the field can be derived from a scalar potential function ($\vec{F} = \nabla f$).
Geometrically, the curl measures the rotation, twist, or circulation of the field around a point.
To visualize this, imagine the vector field is a flowing river 🌊. If you drop a microscopic, frictionless paddlewheel into the water at a specific point and hold its axis in place, will the water make it spin?
Let’s compute the curl for several fields to see this geometry in action.
Consider a velocity field $\vec{v}$ representing a fluid rotating around the z-axis at a constant angular velocity $\omega$. The velocity field is given by $\vec{v} = \langle -\omega y, \omega x, 0 \rangle$. Let’s compute its curl:
$ \nabla \times \vec{v} = \left( \frac{\partial R}{\partial y} - \frac{\partial Q}{\partial z} \right) \hat{\mathbf{i}} - \left( \frac{\partial R}{\partial x} - \frac{\partial P}{\partial z} \right) \hat{\mathbf{j}} + \left( \frac{\partial Q}{\partial x} - \frac{\partial P}{\partial y} \right) \hat{\mathbf{k}}$
Compute each term: $\frac{\partial R}{\partial y} = 0, \frac{\partial Q}{\partial z} = 0, \frac{\partial R}{\partial x} = 0, \frac{\partial P}{\partial z} = 0, \frac{\partial Q}{\partial x} = \omega, \quad \frac{\partial P}{\partial y} = -\omega.$
Substitute these into the curl formula: $\nabla \times \vec{v} = (0 - 0) \hat{\mathbf{i}} - (0 - 0) \hat{\mathbf{j}} + (\omega - (-\omega)) \hat{\mathbf{k}} = 2\omega \hat{\mathbf{k}} $
The Physics Connection: The curl captures the rotational aspect of the fluid perfectly. The magnitude $2\omega$ reveals that the microscopic curl is exactly twice the macroscopic angular velocity of the fluid. The direction $\hat{\mathbf{k}}$ (the unit vector along the positive z-axis) confirms the fluid is rotating in the xy-plane according to the right-hand rule.
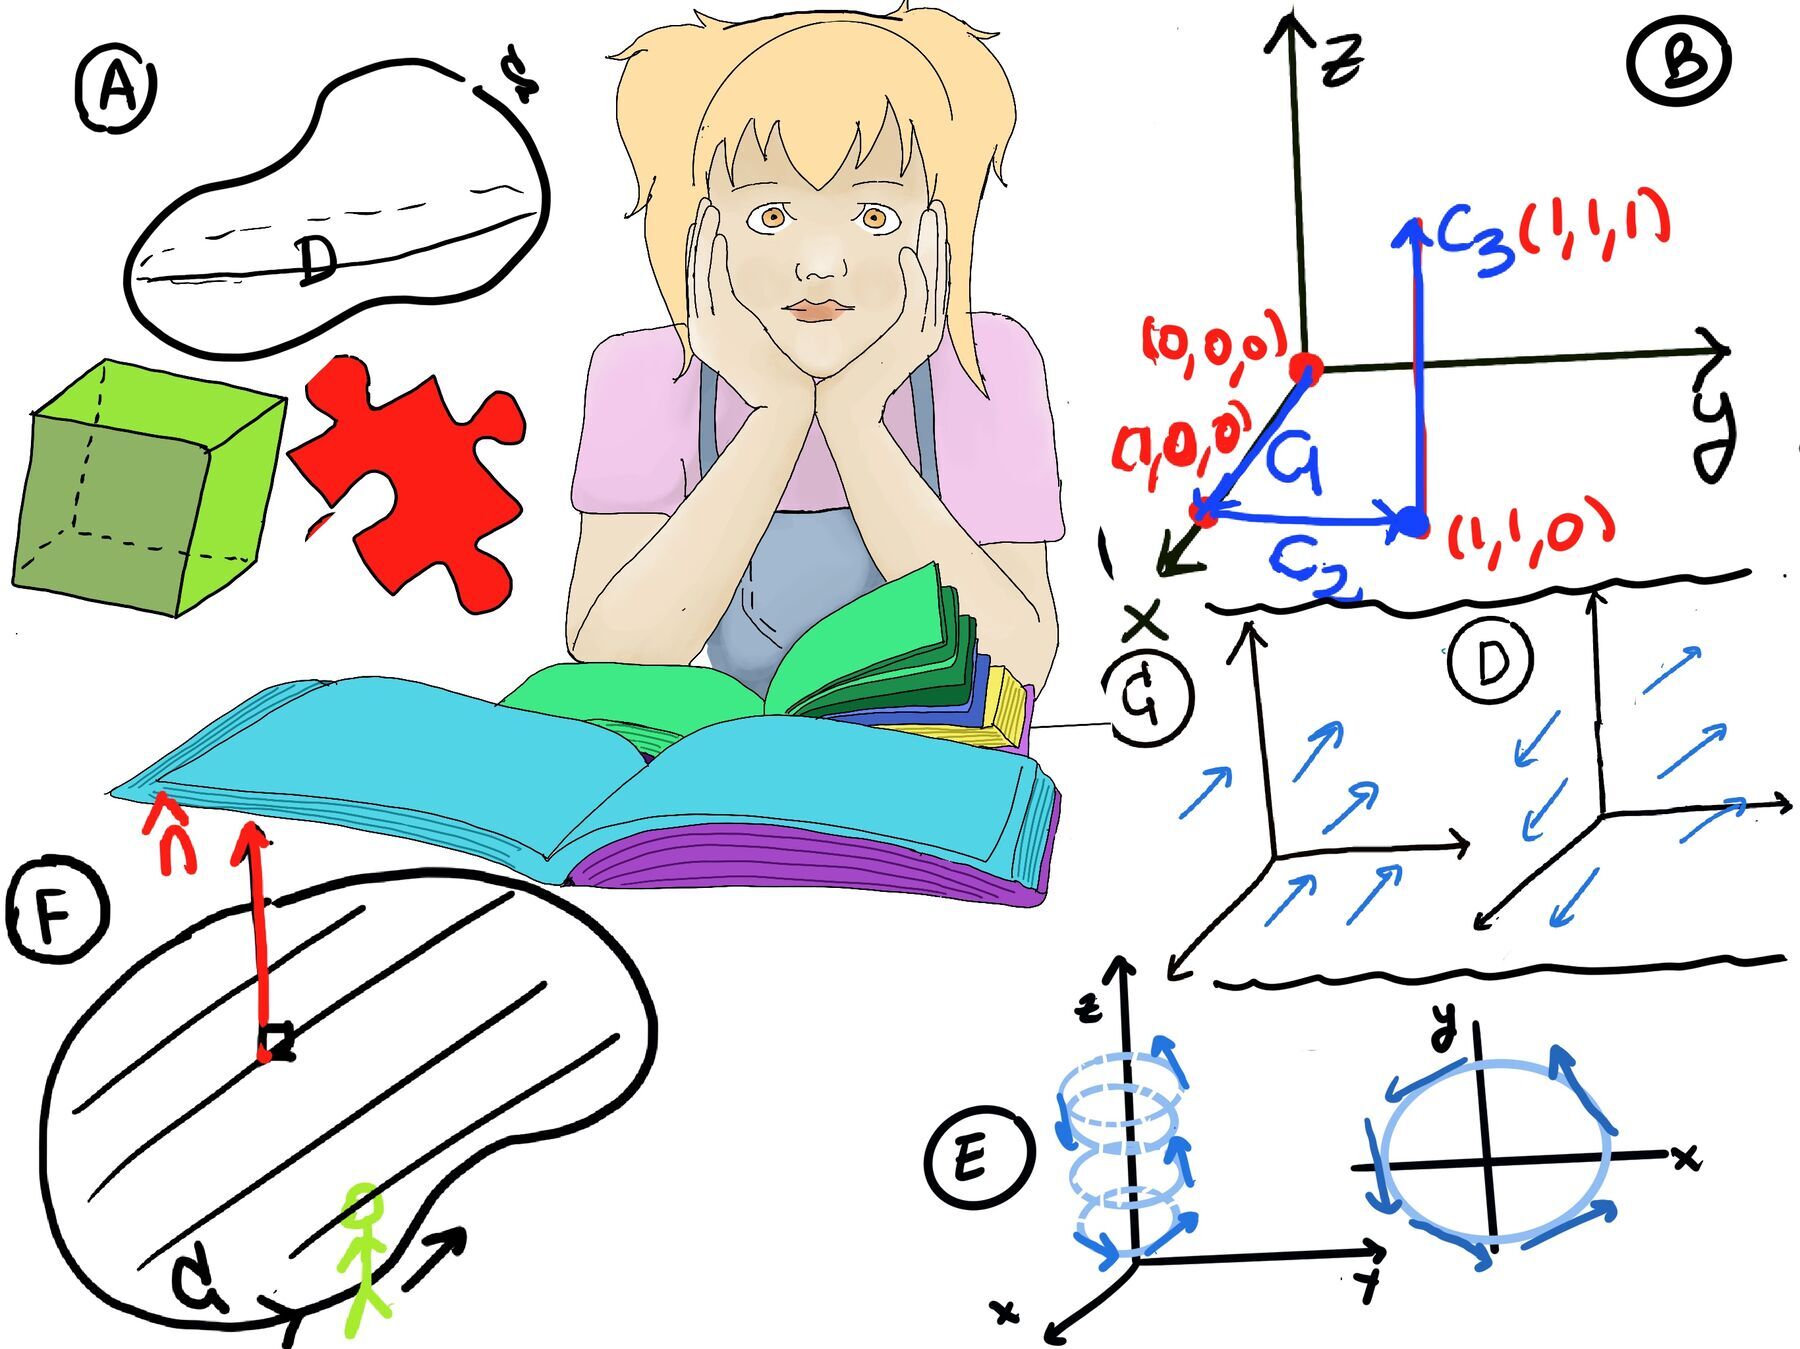
Let $\vec{F} = \langle a, b, c \rangle$, where $a$, $b$, and $c$ are constants. (Figure C). This vector field is constant, meaning that the components $a, b$, and $c$ do not depend on the coordinates $x, y$, or $z$. Since the field does not change, the partial derivatives of its components are all zero. This means that a constant field has no rotational component. It is a simple, uniform field with no twisting or rotation anywhere.
$\operatorname{curl}(\vec{F}) = \nabla \times \vec{F} = \begin{vmatrix}\hat{\mathbf{i}} & \hat{\mathbf{j}} & \hat{\mathbf{k}}\\\ \frac{\partial }{\partial x} & \frac{\partial }{\partial y} & \frac{\partial }{\partial z}\\\ a & b & c\end{vmatrix} = (\frac{\partial c}{\partial y}-\frac{\partial b}{\partial z})\hat{\mathbf{i}}-(\frac{\partial c}{\partial x}-\frac{\partial a}{\partial z})\hat{\mathbf{j}} + (\frac{\partial b}{\partial x}-\frac{\partial a}{\partial y})\hat{\mathbf{k}} = \langle 0, 0, 0\rangle $
Consider the vector field $\vec{F} = \langle x, 0, 0\rangle $ (Figure D).
In this case, the vector field only depends on the x-coordinate. The field points in the x-direction, and its magnitude increases as x increases.
$\operatorname{curl}(\vec{F}) = \nabla \times \vec{F} = \begin{vmatrix}\hat{\mathbf{i}} & \hat{\mathbf{j}} & \hat{\mathbf{k}}\\\ \frac{\partial }{\partial x} & \frac{\partial }{\partial y} & \frac{\partial }{\partial z}\\\ x & 0 & 0\end{vmatrix} = (\frac{\partial 0}{\partial y}-\frac{\partial 0}{\partial z})\hat{\mathbf{i}}-(\frac{\partial 0}{\partial x}-\frac{\partial x}{\partial z})\hat{\mathbf{j}} + (\frac{\partial 0}{\partial x}-\frac{\partial x}{\partial y})\hat{\mathbf{k}} = \langle 0, 0, 0\rangle $.
This field has no rotational component, but it does have nonzero divergence: $\operatorname{div}(\vec{F}) = \nabla \cdot \vec{F} = \frac{\partial x}{\partial x} + \frac{\partial 0}{\partial y} + \frac{\partial 0}{\partial z} = 1 + 0 + 0 = 1.$ Thus, this field spreads out (diverges) as $x$ increases, but it does not twist or rotate.
Consider the vector field $\vec{F} = \langle -y, x, 0\rangle $ (Figure E).
This field clearly rotates counterclockwise around the z-axis.
We can compute its curl to confirm the rotational component: $\operatorname{curl}(\vec{F}) = \nabla \times \vec{F} = \begin{vmatrix}\hat{\mathbf{i}} & \hat{\mathbf{j}} & \hat{\mathbf{k}}\\\ \frac{\partial }{\partial x} & \frac{\partial }{\partial y} & \frac{\partial }{\partial z}\\\ -y & x & 0\end{vmatrix}$
Evaluating the determinant: $(\frac{\partial 0}{\partial y}-\frac{\partial x}{\partial z})\hat{\mathbf{i}}-(\frac{\partial 0}{\partial x}-\frac{\partial (-y)}{\partial z})\hat{\mathbf{j}} + (\frac{\partial x}{\partial x}-\frac{\partial (-y)}{\partial y})\hat{\mathbf{k}} = \langle 0-0, 0-0, 1-(-1)\rangle = \langle 0, 0, 2\rangle$.
Conclusion. This field has a rotational component around the $z$-axis, with a strength of 2. The positive value indicates a counterclockwise rotation in the $xy$-plane.
Consider the vector field $\vec{F} = \langle \cos(xy), \sin(xz), xz^2\rangle $
This field has components that are more complex and depend on products of variables. Let’s compute its curl:
$\operatorname{curl}(\vec{F}) = \nabla \times \vec{F} = \begin{vmatrix}\hat{\mathbf{i}} & \hat{\mathbf{j}} & \hat{\mathbf{k}}\\\ \frac{\partial }{\partial x} & \frac{\partial }{\partial y} & \frac{\partial }{\partial z}\\\ \cos(xy) & \sin(xz) & xz^2\end{vmatrix}$
Let’s evaluate the cross-derivatives carefully:
Combining these components, we get: $\nabla \times \vec{F} = \langle -x\cos(xz), -z^2, z\cos(xz) + x\sin(xy) \rangle$
Conclusion. This result indicates that the field has a highly nontrivial rotational component. A paddlewheel placed in this field will continuously change its axis of rotation and its spin speed depending on its exact $(x,y,z)$ coordinates!
Theorem. Curl of the Gradient of a Function. If $f$ is a scalar function of three variables that has continuous second-order partial derivatives, then $\operatorname{curl}(\nabla f)=0.$ In words, the gradient of a scalar function always produces a vector field with no rotational component.
Proof:
Given a scalar function f with continuous second-order partial derivatives, let’s compute the curl of the gradient of $f$.
The gradient of f is given by: $\nabla f = \langle \frac{\partial f}{\partial x}, \frac{\partial f}{\partial y}, \frac{\partial f}{\partial z}\rangle = \langle f_x, f_y, f_z\rangle$
Now, to compute the curl of the gradient $\nabla f$: $\operatorname{curl}(\nabla f) = \nabla \times \nabla f = \begin{vmatrix}\hat{\mathbf{i}} & \hat{\mathbf{j}} & \hat{\mathbf{k}}\\\ \frac{\partial }{\partial x} & \frac{\partial }{\partial y} & \frac{\partial }{\partial z}\\\ f_x & f_y & f_z\end{vmatrix} = \langle f_{zy}-f_{yz}, -(f_{zx}-f_{xz}), f_{yx}-f_{xy}\rangle = \langle f_{zy}-f_{yz}, f_{xz}-f_{zx}, f_{yx}-f_{xy}\rangle $
Since f has continuous second order partial derivatives, by Clairaut’s theorem or Schwarz’s theorem, the mixed partial derivatives are equal (symmetry of second derivatives) $f_{zy} = f_{yz}, f_{xz}= f_{zx}, f_{yx} = f_{xy}$
Therefore, $\operatorname{curl}(\nabla f) = \langle f_{zy}-f_{yz}, f_{xz}-f_{zx}, f_{yx}-f_{xy}\rangle = \langle 0, 0, 0\rangle $
This theorem is the mathematical backbone of classical physics. It proves that any force field derived from a potential energy landscape (like gravity or electrostatics) cannot make an object spin in endless loops for free, thereby preserving the Law of Conservation of Energy.
A vector field $\vec{F}$ is said to be conservative if there exists a scalar potential function $f$ such that $\vec{F} = \nabla f.$ In other words, a conservative vector field is one that can be expressed as the gradient of some scalar function.
From our previous theorems, we know that the curl of the gradient of any twice-differentiable scalar function is identically the zero vector: $\operatorname{curl}(\nabla f) = \vec{0}$.
Therefore, if $\vec{F}$ is conservative then $\operatorname{curl}\vec{F} = \operatorname{curl}(\nabla f)$ =[Th. Curl of the Gradient of a Function] $\vec{0}$. In words, the curl of a conservative vector field is $\vec{0}$. This is a key characteristic of conservative fields: they have absolutely no microscopic rotational component. The converse is also true, but only if the space the vector field lives in is topologically well-behaved.
For a vector field $\vec{F}=\langle P, Q, R\rangle $ to be conservative, the following conditions must hold simultaneously:
These conditions ensure that the vector field behaves well enough to have a potential function.
The Physics Connection: The concept of a conservative field is the mathematical foundation of potential energy. In an electrostatic field $\vec{E}$, the work done moving an electron from point A to point B depends only on the starting and ending points, not the path taken. This is because $\vec{E}$ is conservative ($\operatorname{curl}(\vec{E}) = \vec{0}$), meaning it can be described entirely by a scalar potential function: Voltage ($V$). In physics, we usually add a negative sign: $\vec{E} = -\nabla V$.
To summarize: The curl must be zero, the partial derivatives must be continuous, and the domain must be open and simply connected.
Is $\vec{F} = \langle x^2y, xyz, -x^2y^2\rangle $ conservative? If so, find its potential function.
Step 1. The Curl Condition. The first condition for a vector field to be conservative is that its curl must be zero: $\operatorname{curl}(\vec{F})=\vec{0}$.
$\operatorname{curl}(\vec{F}) = \nabla \times \vec{F} = \begin{vmatrix}\hat{\mathbf{i}} & \hat{\mathbf{j}} & \hat{\mathbf{k}}\\\ \frac{\partial }{\partial x} & \frac{\partial }{\partial y} & \frac{\partial }{\partial z}\\\ x^2y & xyz & -x^2y^2\end{vmatrix}$
Let’s expand the determinant:
Combining these gives the curl vector: $\operatorname{curl}(\vec{F}) = \langle -(2x^2y + xy), 2xy^2, yz - x^2 \rangle$
Because $\operatorname{curl}(\vec{F}) \neq \vec{0}$, this field fails the very first condition.
Conclusion: The vector field is not conservative, meaning that there is no scalar potential function $f$ that can generate this field.
To determine if a field is conservative, it must satisfy three rigorous mathematical conditions. If all three hold, the field is a gradient of a scalar potential, meaning the work done by the field is path-independent.
The Curl Condition. The first condition for a vector field to be conservative is that its curl must be zero: $\operatorname{curl}(\vec{F})=\vec{0}$.
We compute the curl using the del operator ($\nabla$): $\operatorname{curl}(\vec{F}) = \nabla \times \vec{F} = \begin{vmatrix}\hat{\mathbf{i}} & \hat{\mathbf{j}} & \hat{\mathbf{k}}\\\ \frac{\partial }{\partial x} & \frac{\partial }{\partial y} & \frac{\partial }{\partial z}\\\ z & 2yz & x+y^2\end{vmatrix}$
Evaluating the determinant: $\operatorname{curl}(\vec{F})= \langle 2y-2y, 1-1, 0-0\rangle = \langle 0, 0, 0\rangle $
Continuous First-Order Partial Derivatives. The second condition is that the vector field components must have continuous first-order partial derivatives. The components of $\vec{F}$ are: $P = z, Q = 2yz$, and $R = x + y^2$. All of these are polynomials, and polynomials have continuous partial derivatives everywhere. Thus, the second condition is also satisfied.
Open and Simply Connected Domain. The domain $D$ of $\vec{F}$ must be open and simply connected. The domain $D$ is $\mathbb{R}^3$ is indeed open and simply connected. There are no topological holes, infinite tunnels or obstacles in $\mathbb{R}^3$, meaning that any loop in the domain can be smoothly contracted to a single point.
Since all three conditions are satisfied (curl is zero, continuous partial derivatives, and an open and simply connected domain), the vector field $\vec{F}$ is unequivocally conservative.
Since $\vec{F}$ is conservative, there exists a scalar potential function $f$ such that $\vec{F} = \nabla f$. We need to find $f$ such that: $f_x = z, f_y = 2yz, f_z = x + y^2$.
$f_x = P = z$. First, integrate $f_x$ with respect to $x$, $\int \frac{\partial f}{\partial x}dx = \int zdx$] $f = xz + g(y, z)$, where $g(y, z)$ is an arbitrary function of $y$ and $z$ (since we are treating $y$ and $z$ as constants when integrating with respect to $x$).
Next, differentiate $f$ with respect to $y$. $\frac{\partial f}{\partial y} = \frac{\partial }{\partial y}(xz + g(y, z)) = \frac{\partial g}{\partial y}$. Set this equal to $f_y = Q = 2yz$, $\frac{\partial g}{\partial y}=2yz$ and integrate with respect to $y, g(y, z) = y^2z + h(z)$ where $h(z)$ is an unknown function of $z$.
Finally, differentiate $f$ with respect to $z$. $\frac{\partial f}{\partial z} = \frac{\partial }{\partial z}(xz + y^2z + h(z)) = x + y^2 + h'(z)$. Set this equal to $f_z = R = x + y^2, x + y^2 + h'(z) = x + y^2 \implies h'(z) = 0 \implies h(z) = c.$
We can ignore the constant $C$ when computing the potential function since it does not affect the gradient: $f(x, y, z) = xz + y^2z$.

Step 1. Recall the Divergence Theorem.
The flux of a vector field through a surface is a measure of how much or, more precisely, the net rate, at which the field “flows” or “passes” through that given surface. In this problem, instead of directly calculating the flux through the surface, we can use the Divergence Theorem (also known as Gauss’s Theorem), which relates the flux through a closed surface to the divergence of the vector field over the volume enclosed by the surface.
The Divergence Theorem states that the flux of a vector field $\vec{F}$ through a closed surface $S$ is equal to the integral of the divergence of $\vec{F}$ over the volume $D$ enclosed by the surface: $\oiint_S \vec{F} \cdot d\vec{S} = \iiint_{D} \operatorname{div}(\vec{F}) dV = \iiint_{D} \nabla \cdot \vec{F} dV$
Step 2. Calculate the Divergence of $\vec{F}$: $\nabla \cdot \vec{F} = P_x +Q_y + R_z$
Given: $P = x^4y, Q = -2x^3y^2, R = z^2$, we get: $\nabla \cdot \vec{F} = \frac{\partial }{\partial x}(x^4y)+\frac{\partial }{\partial y}(-2x^3y^2)+\frac{\partial }{\partial z}(z^2) = 4x^3y -4x^3y + 2z = 2z.$
Step 3. Set Up the Volume Integral
The volume integral of the divergence over the region D is given by: $\int \int \int_{D} (\nabla \cdot \vec{F})dV = \int \int \int_{D} 2zdV$
To evaluate this, we switch to cylindrical coordinates because the region is symmetric about the $z$-axis. In cylindrical coordinates: $x = r\cos(\theta), y = r\sin(\theta), z = z$, and $dV = r\, dr\, d\theta\, dz$.
The limits of integration are: $0 \leq \theta \leq 2\pi, 0 \leq r \leq R$ (the radius of the cylinder $x^2+y^2 = R^2$), and $z$ from $0$ to $h$ (the solid cylinder is bounded by the planes $z = 0$ and $z = h$).
Therefore, $\operatorname{Flux} = \int_{0}^{2\pi}\int_{0}^{R}\int_{0}^{h} (2z) r\, dz\, dr\, d\theta$
Evaluate the inner integral with respect to $z$: $\int_{0}^{h} (2z)r\, dz = \big[ rz^2 \big]_{0}^{h} = rh^2$.
Middle integral with respect to $r$: $\int_{0}^{R} rh^2 dr = \frac{1}{2}h^2r^2\bigg|_{0}^{R} = \frac{1}{2}h^2R^2$.
Outer integral with respect to $\theta$: $\int \int \int_{D} (\nabla \cdot \vec{F})dV = \int \int \int_{D} 2zdV = \int_{0}^{2\pi} \frac{1}{2}h^2R^2d\theta = \frac{1}{2}h^2R^2\theta\bigg|_{0}^{2\pi} = \frac{1}{2}h^2R^2\cdot 2\pi = \pi\, h^2\, R^2$
Conclusion. The flux of the vector field $\vec{F} = \langle x^4y, -2x^3y^2, z^2\rangle $ through the surface of the solid bounded by the planes $z = 0, z = h$ and the cylinder $x^2 + y^2 = R^2$ is $\pi\, h^2\, R^2$. This result provides a measure of how much of the vector field flows through the cylindrical surface.

JustToThePoint Copyright © 2011 - 2026 Anawim. ALL RIGHTS RESERVED. Bilingual e-books, articles, and videos to help your child and your entire family succeed, develop a healthy lifestyle, and have a lot of fun. Social Issues, Join us.
This website uses cookies to improve your navigation experience.
By continuing, you are consenting to our
use of cookies, in accordance with our Cookies Policy and
Website Terms and Conditions of use.